QuickBrick Delta Robot
A delta robot with three parallel arms that sorts blocks automatically using digital vision and an optimal trajectory planner.
- Robot arm
- Open source
- 3D printable
Suggested by Robotheca, created by @QuickBrickDelta (opens in a new tab), from github.com/QuickBrickDelta/Delta_robot (opens in a new tab). Pinned to commit f2e4724 (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
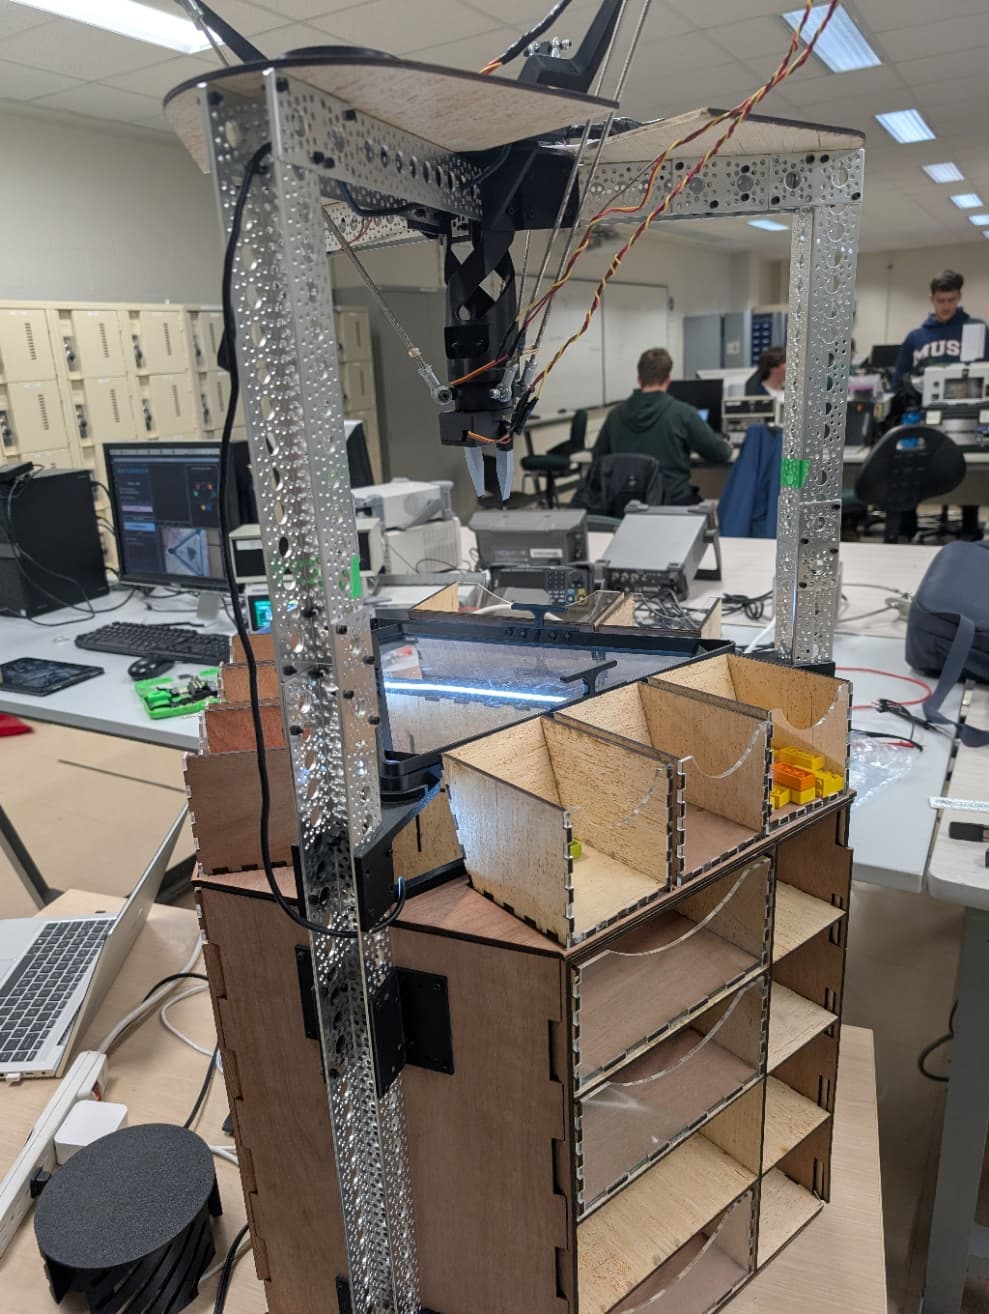
3D preview converted from github.com/QuickBrickDelta/Delta_robot at f2e4724, under MIT. View the original files from GitHub (31.9 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Sorts colored blocks automatically using a camera and numeric vision (HSV color detection).
- Converts camera pixel positions to centimeter coordinates via homography.
- Optimizes the sorting order with a Branch & Bound algorithm for the asymmetric traveling salesman problem.
- Controls three parallel delta arms through inverse kinematics.
- Provides a PyQt6 control interface with real-time 3D visualization and drag-and-drop bin configuration.
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @QuickBrickDelta (README.md), under MIT.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Dynamixel XC430 servo motors.
- OpenRB-150 controller board running C++ firmware.
- Raspberry Pi with a camera.
Connections
- Raspberry Pi communicates with the Arduino/OpenRB-150 over a serial protocol.
- The hardware wiring diagram is described in docs/hardware.md, which the README points to but does not detail here.