Mujina
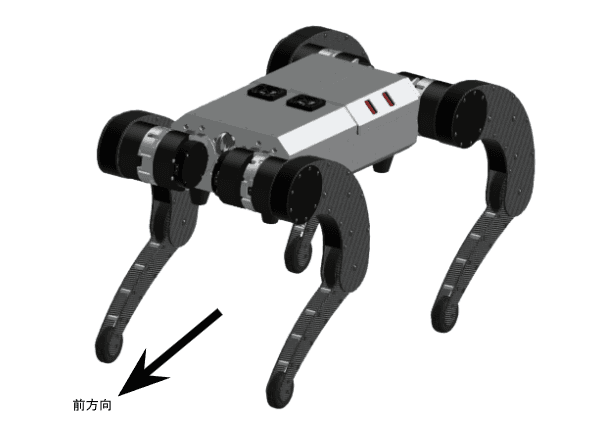
A quadruped walking robot (Mujina) whose CAD data is published in this repository.
- Quadruped
- Open source
- ROS 2
- 3D printable
Suggested by Robotheca, created by @rt-net (opens in a new tab), from github.com/rt-net/Mujina_Hardware (opens in a new tab). Pinned to commit 6eaa30f (opens in a new tab).
- Hardware license
- CC-BY-SA-4.0 (opens in a new tab)
- Software license
- CC-BY-SA-4.0 (opens in a new tab)
- Commercial use
- Allowed
Photo
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Set up the LattePanda IOTA PC following the mujina_ros README
- 2Configure LattePanda Auto Power-On
- 3Write motor IDs and update motor firmware using motor_tool.md
- 4Write firmware to the USB 9-axis IMU module and USB-CAN FD interface, then insta
- 5Install the LattePanda IOTA PC inside the robot following lattepanda.md
- 6Wire the motor cables and internal harness following cable.md
- 7Insulate the XT30 (2+2) connectors of motors that have no motor cable connected
The guide appears here as you scroll.
Guide by @rt-net (README.md), under CC-BY-SA-4.0. The English translation is by Robotheca, shared under the same license.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- LATTEPANDA IOTA single-board computer built into the robot
- USB 9-axis IMU sensor module V3 requiring firmware
- WeAct USB-CANFD interface requiring firmware
- Motors with IDs assigned per a motor ID map
Connections
- Motor cables and XT30 (2+2) connectors inside the body, detailed in cable.md
- Unused motor XT30 (2+2) connectors must be insulated