Delta-Bot
A small ESP32-C3 desk robot with an animated OLED face, touch gestures, web-based RC driving, voice commands, clock, to-do list, Pomodoro timer and virtual pet.
- Home
- Open source
- arduino
- 3D printable
Suggested by Robotheca, created by @MehediEEE45 (opens in a new tab), from github.com/MehediEEE45/Delta-Bot (opens in a new tab). Pinned to commit 8f51a4c (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
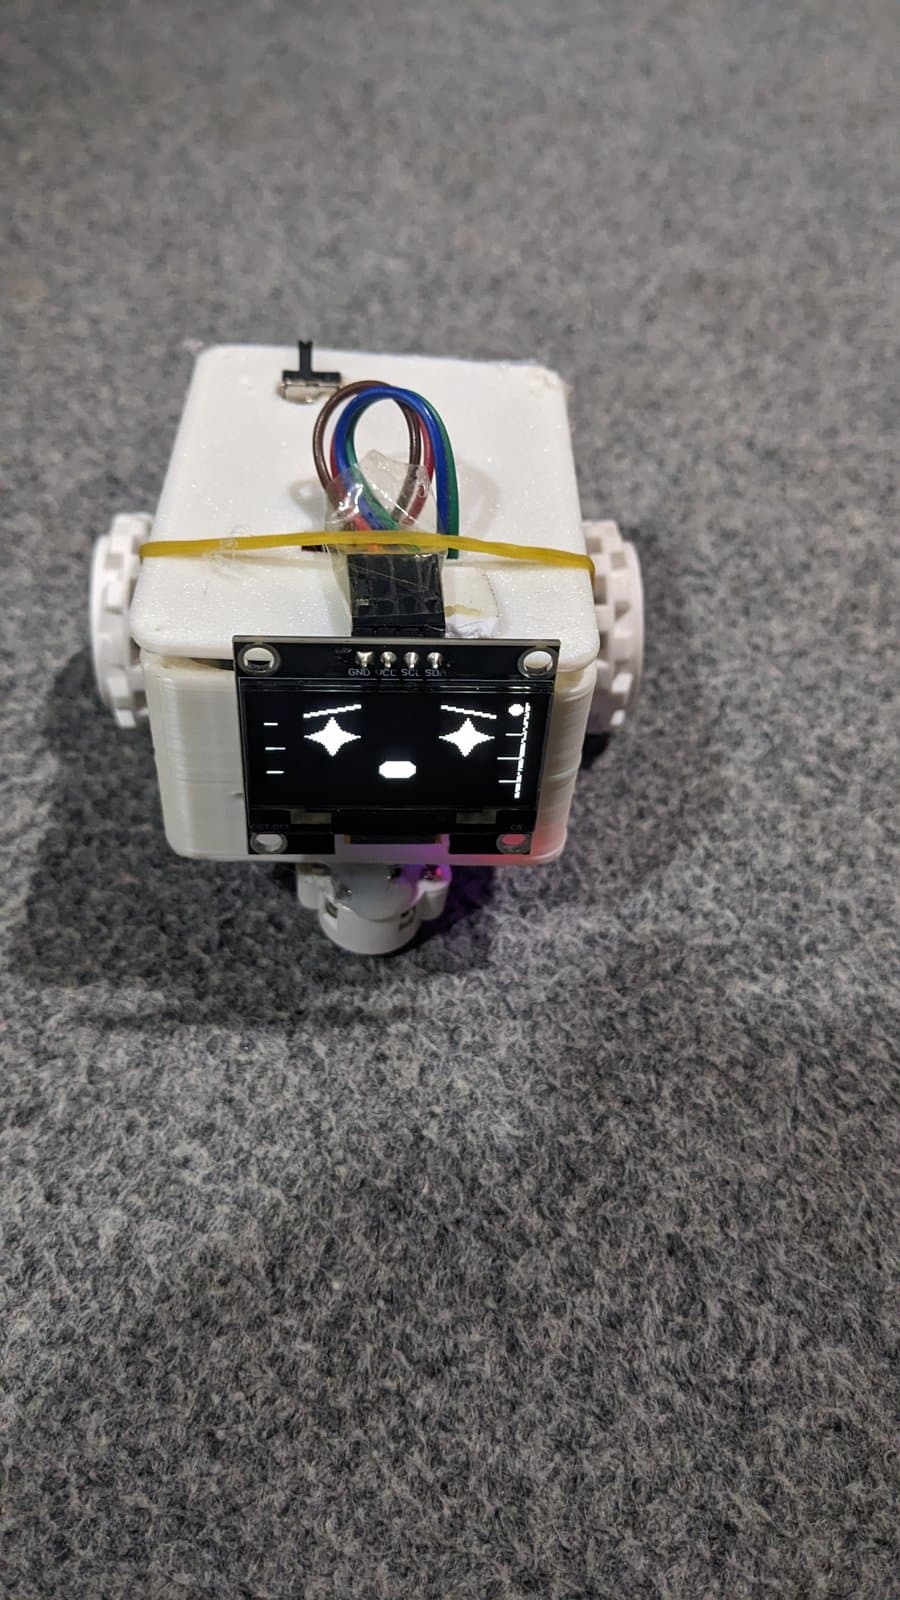
3D preview converted from github.com/MehediEEE45/Delta-Bot at 8f51a4c, under MIT. View the original files from GitHub (372 KB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Shows an animated face with nine expressions on a 128x64 OLED that blinks and moves on its own.
- Responds to taps on a capacitive touch pad: tap to change screens, double tap for random expression, hold to sleep.
- Drives two motors from a web page D-pad, with motors stopping after one second without commands.
- Accepts voice commands through the browser's speech recognition on a secure page.
- Shows clock and weather, a to-do list, a Pomodoro timer, a virtual pet, and a 16x16 pixel canvas.
- Can be controlled over USB serial, Bluetooth Low Energy, and a built-in web dashboard.
Bill of materials
7 parts7 of 7 parts shown
| # | Component | Quantity | Est. price | Supplier |
|---|---|---|---|---|
| 1 | ESP32-C3 SuperMini | 1 | – | – |
| 2 | 128×64 OLED, I²C | 1 | – | – |
| 3 | TB6612FNG motor driver | 1 | – | – |
| 4 | N20 gear motors, 6 V | 2 | – | – |
| 5 | TTP223 touch module | 1 | – | – |
| 6 | LiPo 3.7 V, ~1000 mAh | 1 | – | – |
| 7 | Wheels, 34 mm | 2 | – | – |
7 of 7 parts have no price in the source, so there is no parts total. Read from README.md at the pinned commit.
Build guide
The guide appears here as you scroll.
Guide by @MehediEEE45 (README.md), under MIT.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- ESP32-C3 SuperMini microcontroller board (build target esp32-c3-devkitm-1).
- 128x64 OLED display driven over I2C (SSD1306 or SSD1305).
- TB6612FNG dual motor driver, not compatible with DRV8833.
- Two N20 gear motors rated 6 V.
- TTP223 capacitive touch module.
- LiPo 3.7 V cell of about 1000 mAh with a TP4056 charger board that includes DW01 protection.
- A small boost converter to 5 V is recommended for powering the ESP32 from the cell.
Connections
- OLED SDA on GPIO 8 and SCL on GPIO 9 for I2C.
- TTP223 touch signal on GPIO 4.
- TB6612 PWMA on GPIO 3, AIN1 on GPIO 5, AIN2 on GPIO 6.
- TB6612 PWMB on GPIO 0, BIN1 on GPIO 7, BIN2 on GPIO 10, STBY on GPIO 1.
- Motor driver VM is powered from the LiPo rail while VCC takes the 3V3 logic supply.
- All grounds must be connected in common.
- GPIO 8 and 9 are strapping pins and may need pull-ups and short leads if startup is unreliable.
