CM6 V2 Robotic arm
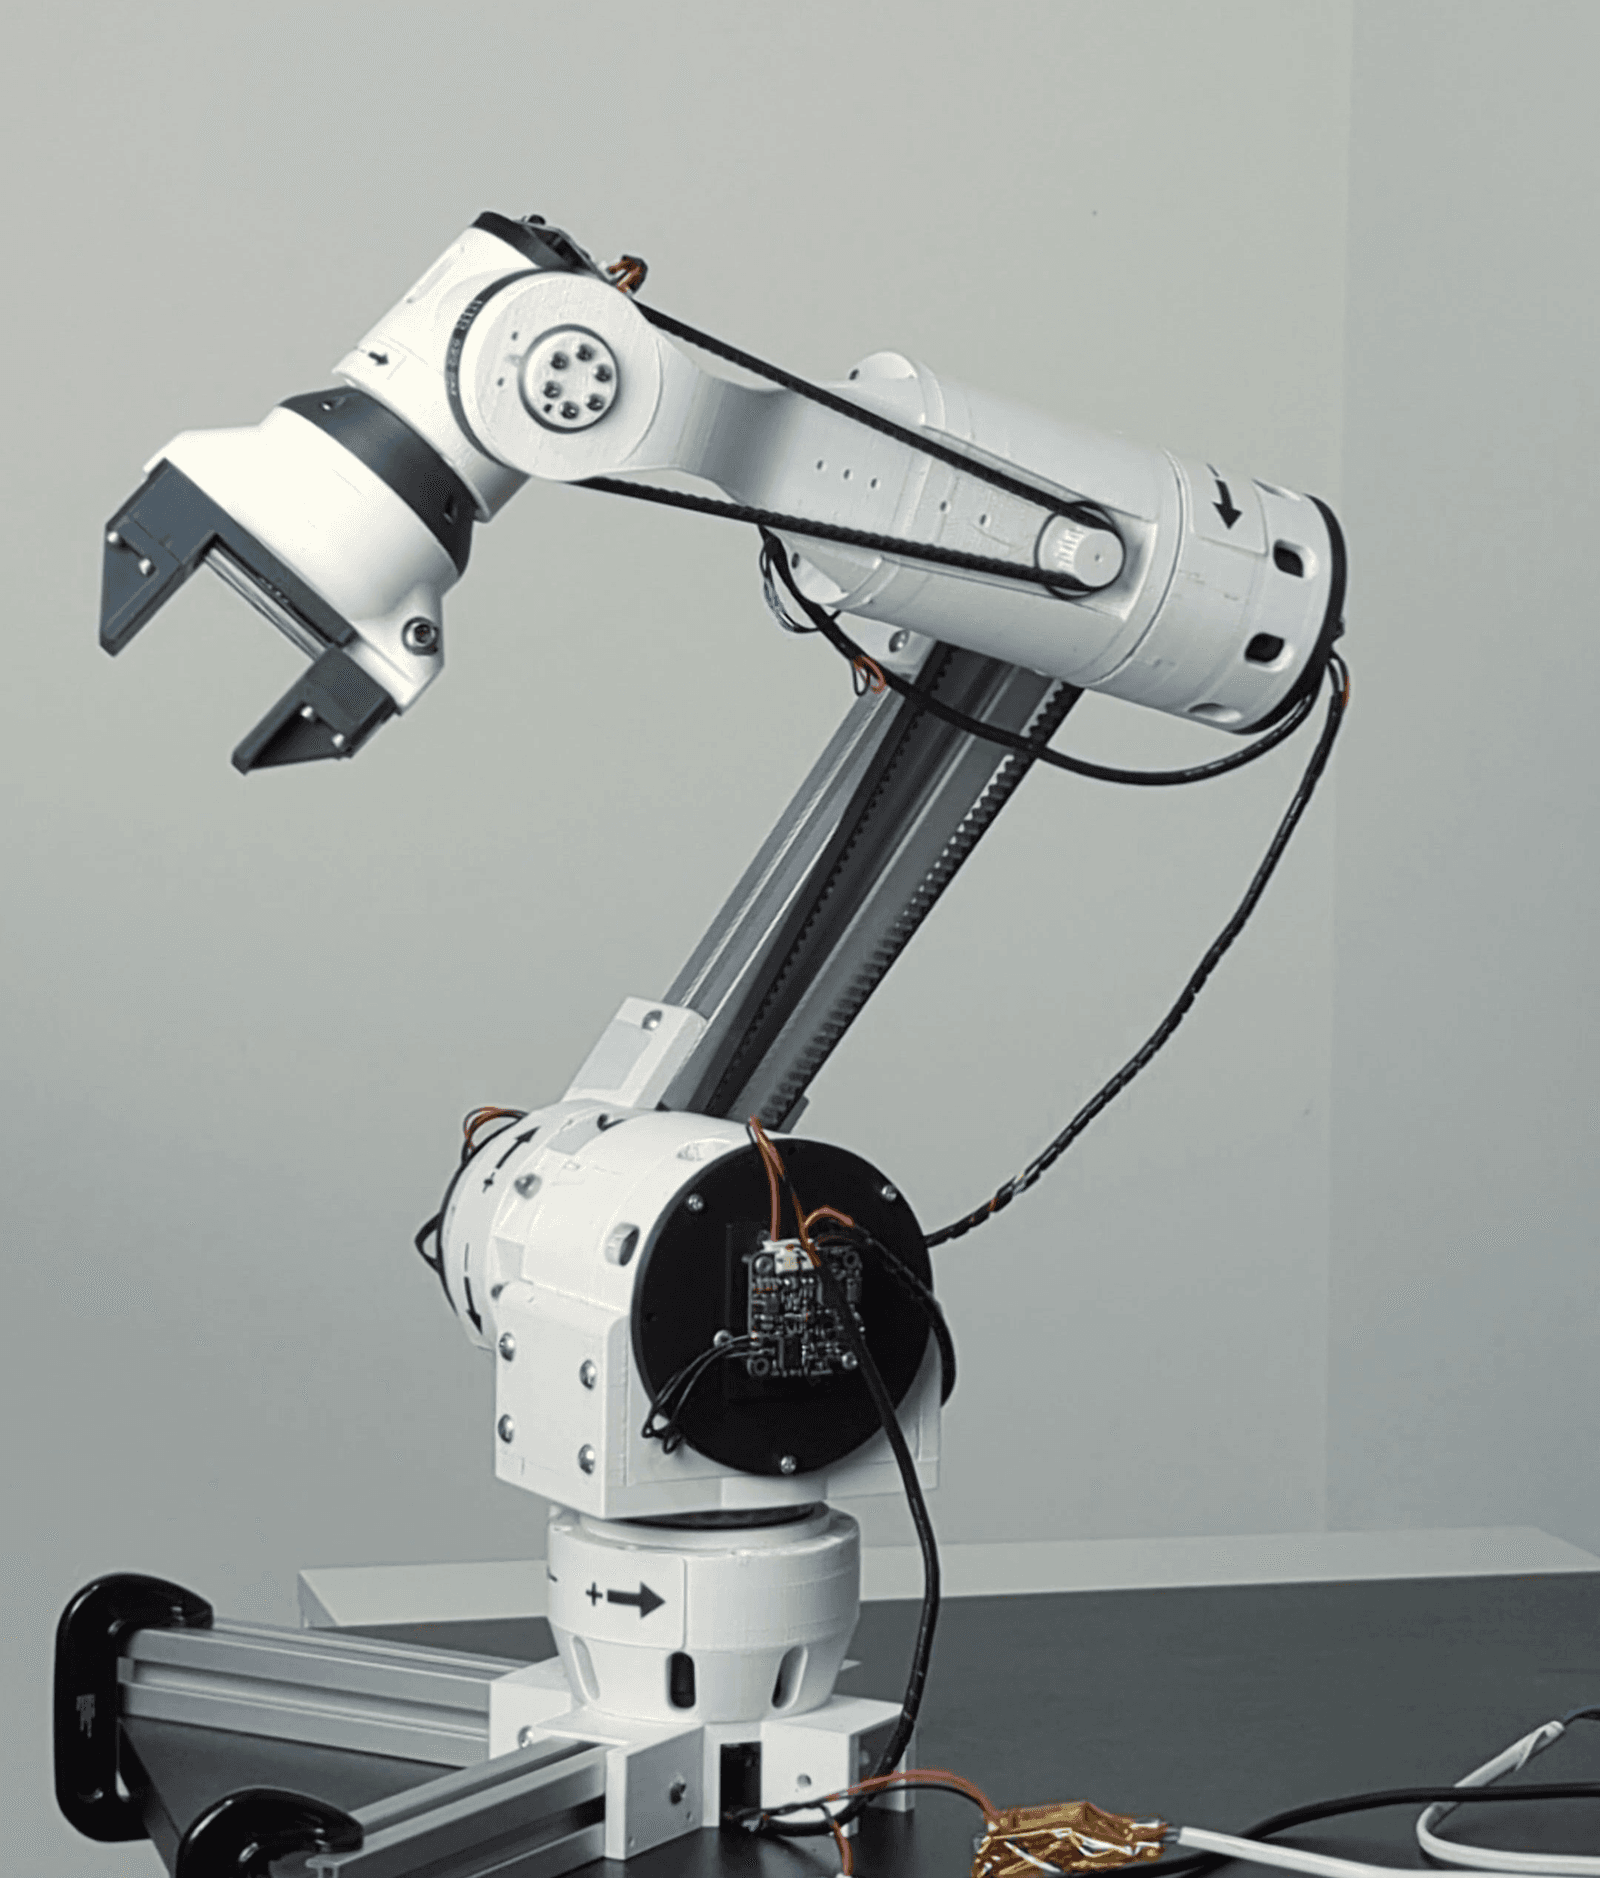
A compliant, safe 6-axis robotic arm built from 3D-printed and aluminum-extrusion parts, intended as a research platform for compliant robotics.
- Robot arm
- Open source
Suggested by Robotheca, created by @Source-Robotics (opens in a new tab), from github.com/Source-Robotics/CM6_COBOT_ROBOT (opens in a new tab). Pinned to commit f4668c1 (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
Photo
What it can do
Written by Robotheca from the project's documents.
- Compliant, safe robotic arm with six joints driven by gimbal BLDC motors through small gearboxes
- Intended as a research platform for compliant and safe robotics
- Joint design can be changed by using different aluminum extrusion sizes or gearbox ratios
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @Source-Robotics (README.md), under MIT.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Six gimbal BLDC motors, each joint paired with a gearbox of 5:1 to 9:1 ratio
- Spectral BLDC motor driver on each joint, mounted on modular actuator designs
Connections
- Each joint's motor is driven by its own Spectral driver mounted on the modular actuator