Zippy
A 3D printed Arduino Nano based two-wheel balancing robot with a custom PCB and optional bumpers.
- Other
- Open source
- arduino
- 3D printable
Suggested by Robotheca, created by @elkayem (opens in a new tab), from github.com/elkayem/ZippyTheBalancingRobot (opens in a new tab). Pinned to commit 7040419 (opens in a new tab).
- Hardware license
- GPL-3.0-only (opens in a new tab)
- Software license
- GPL-3.0-only (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
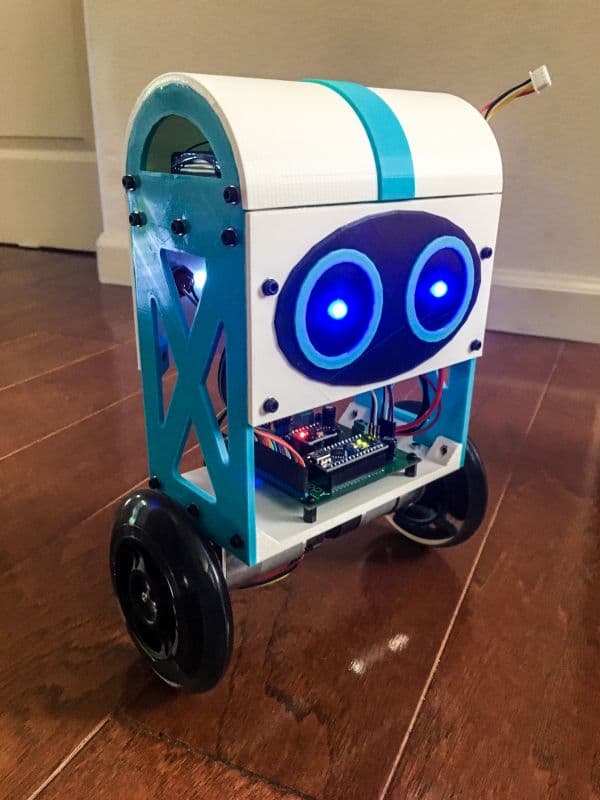
3D preview converted from github.com/elkayem/ZippyTheBalancingRobot at 7040419, under GPL-3.0-only. View the original files from GitHub (3.4 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Balances on two wheels as a self-balancing robot using gyro and accelerometer feedback with PID control.
- Driven by two 30:1 metal gearmotors with encoders.
- Controlled by a remote control with a PWM receiver.
- Optional companion eye display with colored or rainbow LED patterns, controlled from the remote's left throttle stick.
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @elkayem (README.md), under GPL-3.0-only.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Arduino Nano controller.
- Custom PCB or breadboard built from the included schematic.
- 2 x VNH5180A motor drivers.
- 2 x 30:1 Metal Gearmotor 37Dx68L mm with 64 CPR encoders.
- GY-521 MPU-6050 gyro/accelerometer breakout board.
- 16x2 character LCD display.
- 3S 3000mAh LiPo battery.
- Remote control with PWM receiver.
- Two Schottky diodes.
- Resistors, capacitors, 10K trimpot, pushbutton and connectors.
- Optional second Arduino Nano or Pro Mini with two RGB LEDs and six 300 ohm resistors for the eyes.
Connections
- Wiring details are given in the Eagle schematic, which the documents refer to rather than describe.
- The MPU-6050 must be mounted with its +X axis facing the front of the robot.
- Motor leads may need swapping to correct wheel polarity.