Stepping Balancer
A two-wheeled inverted pendulum robot controlled by a Nucleo board and driven by stepper motors.
- Other
- Open source
- 3D printable
Suggested by Robotheca, created by @JunSotohigashi (opens in a new tab), from github.com/JunSotohigashi/stepping-balancer (opens in a new tab). Pinned to commit a1a6221 (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
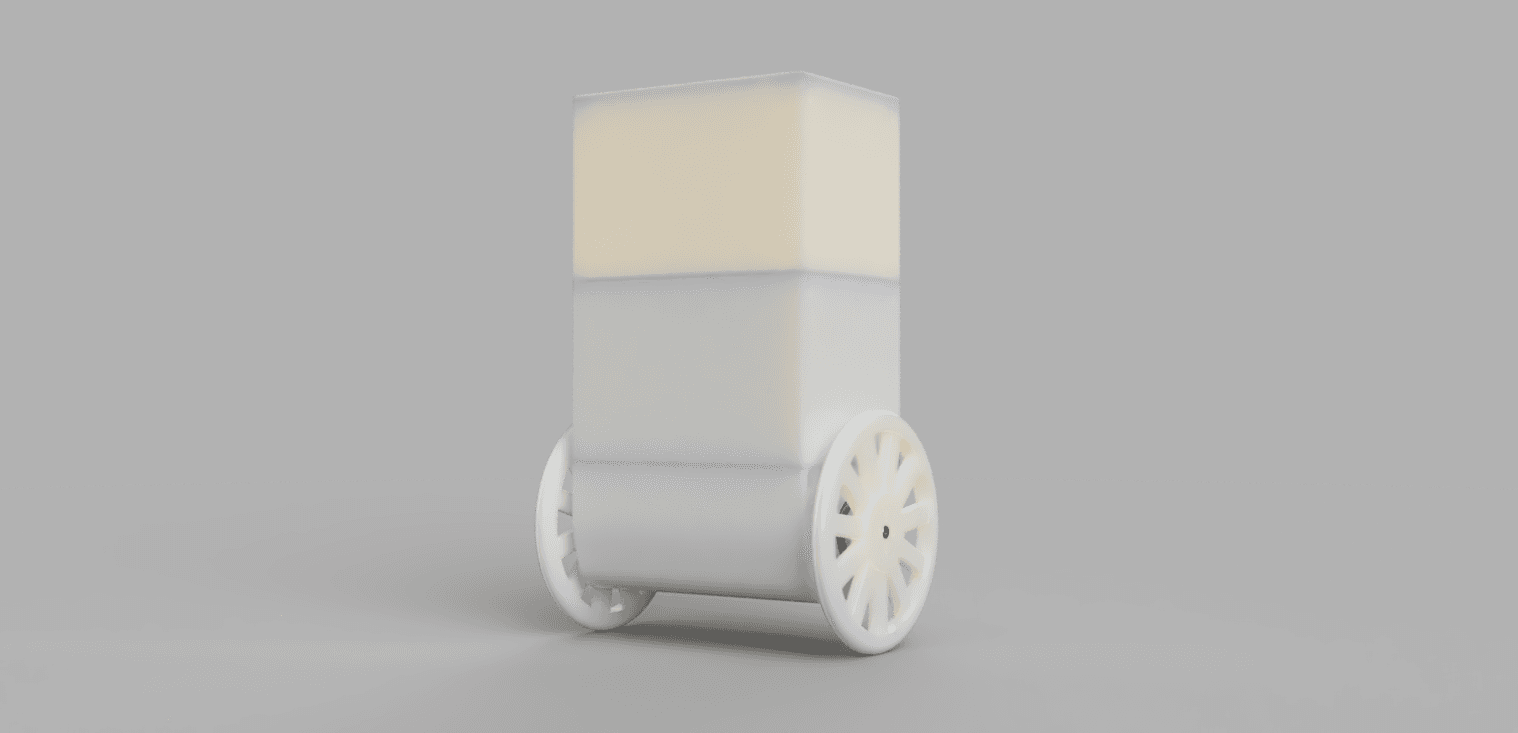
3D preview converted from github.com/JunSotohigashi/stepping-balancer at a1a6221, under MIT. View the original files from GitHub (7.0 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Two-wheeled inverted pendulum (self-balancing) robot driven by stepping motors
- Controlled by a Nucleo board
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @JunSotohigashi (README.md), under MIT. The English translation is by Robotheca, shared under the same license.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Nucleo microcontroller board
- Stepping motors for the two wheels