 3D render
Open source · free files
Cenk AI Desk Robot
Home · Intermediate
- Score
- Buildability 75 out of 100
- Cost
- Not stated
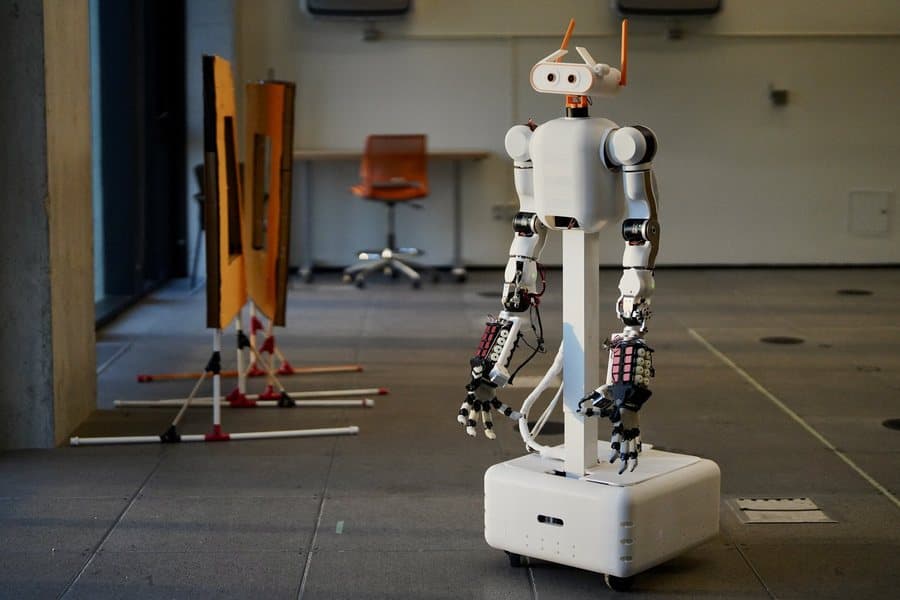
3D preview converted from github.com/robotmabel/open_mabel at 2f9229f, under CERN-OHL-S-2.0. View the original files from GitHub (65.5 MB) (opens in a new tab)
Home
An open-source 56-DOF mobile bimanual robot with a swerve base, lift, torso, active head, two 7-DOF arms and two 17-DOF hands, teleoperated from an Apple Vision Pro.
Some folders have their own license: firmware/swerve_drive/sparkcan_py/ (MIT).
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Suggested by Robotheca, created by @robotmabel (opens in a new tab), from github.com/robotmabel/open_mabel (opens in a new tab), pinned to commit 2f9229f (opens in a new tab). You buy the parts yourself; Robotheca doesn't sell robots.
49 of 49 parts shown
| Item | Part | Qty | Unit price | Amount | Source |
|---|---|---|---|---|---|
| 01 | REV 3in MAXSwerve Module | 3 | $275 | $825≈ €732 | revrobotics.com: buy REV 3in MAXSwerve Module, opens in a new tab |
| 02 | REV MAXSwerve Motor & Controller Bundle | 3 | $280 | $840≈ €746 | revrobotics.com: buy REV MAXSwerve Motor & Controller Bundle, opens in a new tab |
| 03 | Base sheet metal, lower | 1 | $51.75 | $51.75≈ €46 | Custom fabrication |
| 04 | Base sheet metal, upper | 1 | $195.36 | $195.36≈ €173 | Custom fabrication |
| 05 | FlexiSpot E7 Pro lift column | 1 | $399 | $399≈ €354 | flexispot.com: buy FlexiSpot E7 Pro lift column, opens in a new tab |
| 06 | Lift-to-torso adapter | 1 | $59.26 | $59.26≈ €53 | Custom fabrication |
| 07 | Torso output plate | 1 | $55.16 | $55.16≈ €49 | Custom fabrication |
| 08 | Body bottom plate | 1 | $33.55 | $33.55≈ €30 | Custom fabrication |
| 09 | Arm mounting plate | 2 | $13.17 | $26.34≈ €23 | Custom fabrication |
| 10 | Neck mounting plate | 1 | $29.05 | $29.05≈ €26 | Custom fabrication |
| 11 | DAMIAO DM10422P torso actuator | 1 | ¥1,999 | ¥1,999≈ €266 | Taobao |
| 12 | DAMIAO FOCGM43 joint module | 6 | ¥599 | ¥3,594≈ €478 | Taobao |
| 13 | DAMIAO DM4340 joint motor | 4 | ¥882.33 | ¥3,529.32≈ €469 | Taobao |
| 14 | DAMIAO DM8009P joint module | 4 | ¥1,899 | ¥7,596≈ €1,010 | Taobao |
| 15 | OpenArm structural set | 1 | ¥2,699 | ¥2,699≈ €359 | Taobao |
| 16 | Arm harness set | 1 | ¥865 | ¥865≈ €115 | Taobao |
| 17 | Feetech HL3915M servo | 32 | ¥235 | ¥7,520≈ €1,000 | Taobao |
| 18 | Feetech HL3930M servo | 2 | ¥359 | ¥718≈ €96 | Taobao |
| 19 | ST/SC bus servo driver board | 2 | ¥27.65 | ¥55.30≈ €7 | Taobao |
| 20 | Bus servo power distribution board | 2 | ¥18 | ¥36≈ €5 | Taobao |
| 21 | Robotis Dynamixel 2XL430-W250-T | 1 | $149.39 | $149.39≈ €133 | RobotShop: buy Robotis Dynamixel 2XL430-W250-T, opens in a new tab |
| 22 | DAMIAO FOCGM43 neck actuator | 1 | ¥599 | ¥599≈ €80 | Taobao |
| 23 | Aluminium extrusion, cut lengths | 1 | $101.46 | $101.46≈ €90 | McMaster-Carr: buy Aluminium extrusion, cut lengths, opens in a new tab |
| 24 | Extrusion 90 degree corner brackets | 1 | $26.90 | $26.90≈ €24 | amazon.com |
| 25 | Extrusion angled plates | 1 | $20.88 | $20.88≈ €19 | amazon.com |
| 26 | Metric screw assortment | 1 | $13.99 | $13.99≈ €12 | amazon.com |
| 27 | Imperial screw assortment | 1 | $8.99 | $8.99≈ €8 | amazon.com |
| 28 | Neodymium magnets | 1 | $11.99 | $11.99≈ €11 | amazon.com |
| 29 | SODOLA 6-port 2.5 GbE switch | 1 | $49.99 | $49.99≈ €44 | amazon.com |
| 30 | USB expansion board | 1 | $74.99 | $74.99≈ €67 | amazon.com |
| 31 | Battery | 2 | $46.81 | $93.62≈ €83 | amazon.com |
| 32 | Ethernet twinax cable | 1 | $45.99 | $45.99≈ €41 | amazon.com |
| 33 | Wi-Fi antenna cable | 2 | $17.99 | $35.98≈ €32 | amazon.com |
| 34 | Power cable, 6XT | 1 | $24.99 | $24.99≈ €22 | amazon.com |
| 35 | Buck converter 24 V to 12 V | 1 | $18.99 | $18.99≈ €17 | amazon.com |
| 36 | Speaker + USB sound card | 1 | $19.50 | $19.50≈ €17 | amazon.com |
| 37 | Power cord extension | 1 | $16.95 | $16.95≈ €15 | amazon.com |
| 38 | Fuse box | 1 | $15.99 | $15.99≈ €14 | amazon.com |
| 39 | Raspberry Pi Pico | 1 | $15.95 | $15.95≈ €14 | amazon.com |
| 40 | Motor driver | 1 | $9.99 | $9.99≈ €9 | amazon.com |
| 41 | USB-C to USB-A cable | 4 | $6.99 | $27.96≈ €25 | amazon.com |
| 42 | Ethernet patch cable | 2 | $6.99 | $13.98≈ €12 | amazon.com |
| 43 | Protective sleeving, 1/2 in | 2 | $8.99 | $17.98≈ €16 | amazon.com |
| 44 | Protective sleeving, 1/4 in | 1 | $8.99 | $8.99≈ €8 | amazon.com |
| 45 | Custom PCBs | 1 | $0 | $0≈ €0 | JLCPCB: buy Custom PCBs, opens in a new tab |
| 46 | Custom PCB components | 1 | $0 | $0≈ €0 | - |
| 47 | Bambu Lab PLA Basic, Jade White | 4 | $17.24 | $68.96≈ €61 | Bambu Lab: buy Bambu Lab PLA Basic, Jade White, opens in a new tab |
| 48 | Bambu Lab PLA Basic, Black | 2 | $17.24 | $34.48≈ €31 | Bambu Lab: buy Bambu Lab PLA Basic, Black, opens in a new tab |
| 49 | Bambu Lab PLA Basic, Light Gray | 1 | $17.24 | $17.24≈ €15 | Bambu Lab: buy Bambu Lab PLA Basic, Light Gray, opens in a new tab |
≈ € amounts use the ECB reference rate of 4 Nov 2026, for comparison only.
Prices are in several currencies, so there is no parts total.
86/100
Ready to build
How complete the published files are for rebuilding this robot, measured by Robotheca at commit 2f9229f. It isn't a rating of the robot.
The guide appears here as you scroll.
Guide by @robotmabel (README.md), under CERN-OHL-S-2.0 (hardware) and Apache-2.0 (software).
From the parts list.
Found by Robotheca in the project's files at commit 2f9229f, its robot.yaml and Robotheca's notes on its documents. Never guessed; Robotheca doesn't run the code.
Has LeRobot code
In the project files: robot_learning/h5_to_lerobot_v30.pyUses reinforcement learning
In the project files: robot_learning/reinforcement_learningUses reinforcement learning: Isaac Lab
In the project files: calibration/motor_calibration/results/DM-J4340P/isaaclab_actuator.pyUses reinforcement learning: mjlab
In the project files: robot_learning/reinforcement_learning/mjlabUses imitation learning
In the project files: robot_learning/imitation_learningUses a machine-learning library: PyTorch
In the project files: robot_learning/reinforcement_learning/mjlab/src/mjlab/utils/torch.py“Records teleoperation demonstrations as HDF5 episodes and supports imitation learning and reinforcement learning workflows.”
Robotheca's summary: What it can doRobotheca doesn't review code. Read it before running it.
Written by Robotheca from the project's documents, not by its creator.
No software from Robotheca's catalogue found in this robot's files yet. Links come from its robot.yaml, its dependency files read as text, or Robotheca's editors.
Every file of the project, at commit 2f9229f.
Questions and improvements go to the creator's repository.
For the creator: two badges that link back here. The second always shows this page's current label and score.

Markdown (one click selects it)
[](https://robotheca.org/robots/mabel-2) [](https://robotheca.org/robots/mabel-2)
3D renderOpen source · free files
Home · Intermediate
Open source · free files
Home · Intermediate
Open source · free files
Home · Intermediate
≈ € values are approximate, converted at the ECB euro reference rate of 4 Nov 2026. The creator's original price always comes first.