KANI Quadruped
KANI is an open-source quadruped walking robot, a redesign of the KAME robot, built around an ESP8266 and eight servo motors.
- Quadruped
- Open source
- arduino
- 3D printable
Suggested by Robotheca, created by @FredJ21 (opens in a new tab), from github.com/FredJ21/KANI_Quadruped_Bot (opens in a new tab). Pinned to commit b7f4323 (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
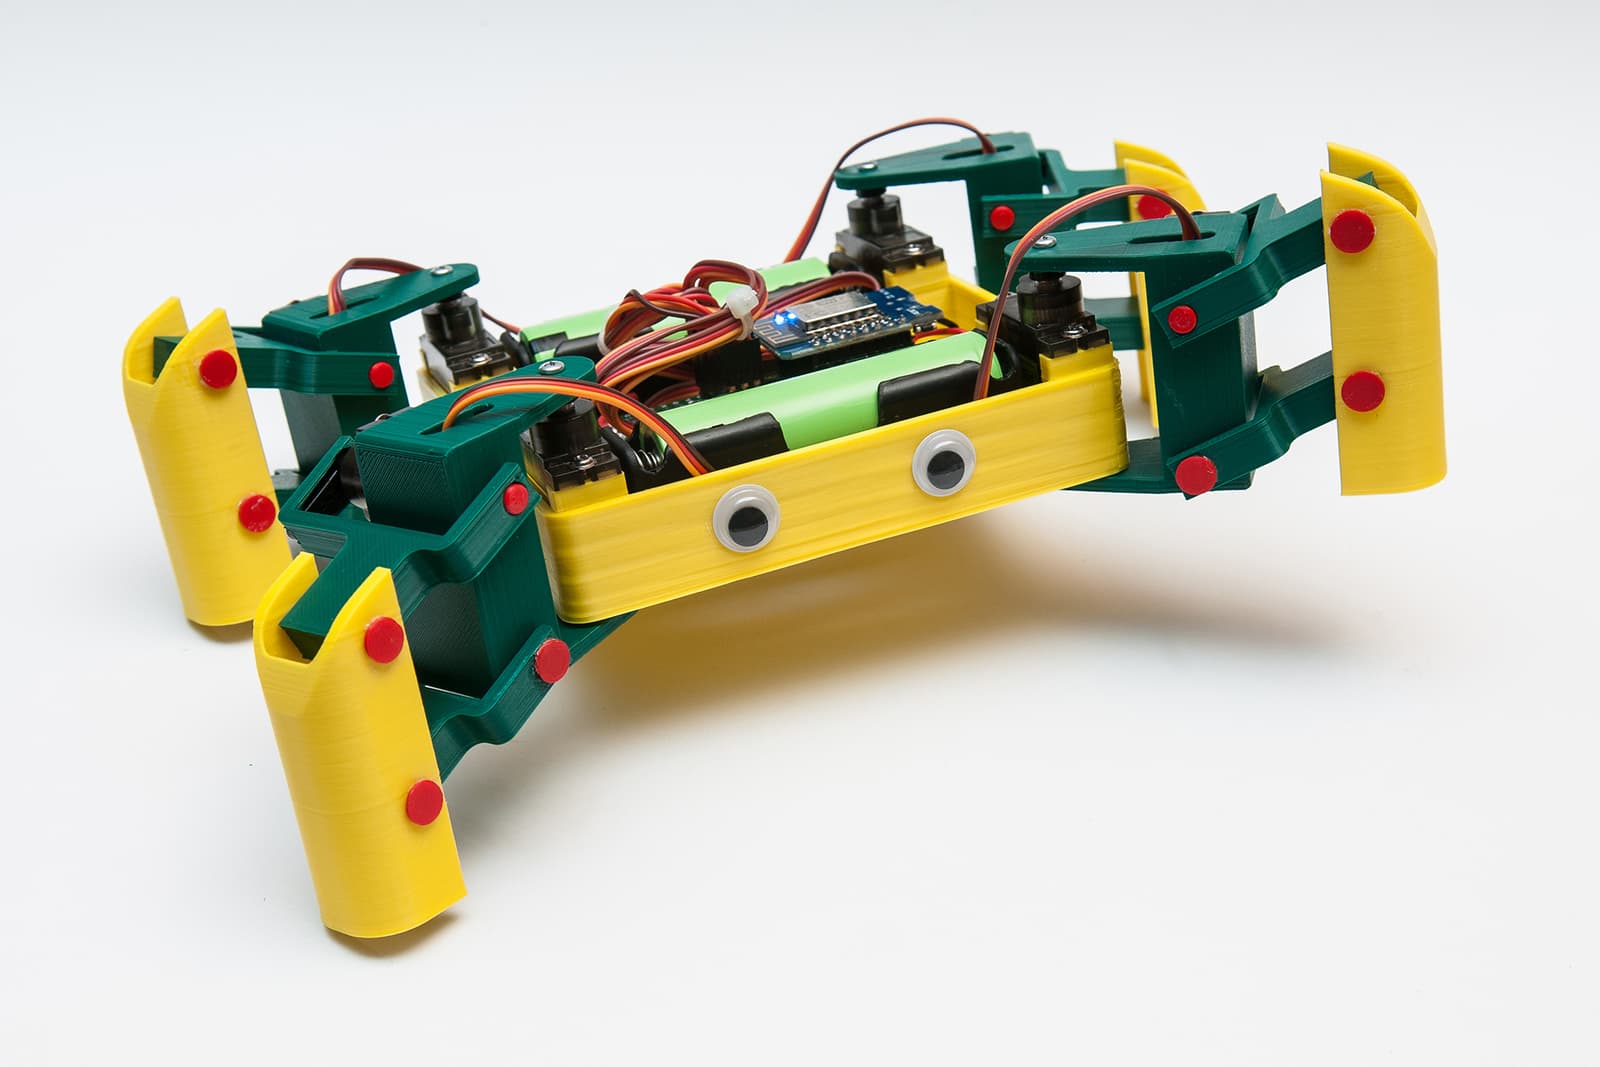
3D preview converted from github.com/FredJ21/KANI_Quadruped_Bot at b7f4323, under MIT. View the original files from GitHub (1.6 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- KANI is a quadruped (four-legged) walking robot, a close relative of the KAME design.
- Parts are redesigned for 3D printing in PLA without support structures or adhesion borders.
- Leg articulation uses no screws for mounting the joints.
- A newer 'BIG KANI' version uses MG996 servo motors.
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @FredJ21 (README.md), under MIT.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- An ESP8266 microcontroller board is the robot's controller.
- Eight MG90S metal-gear servo motors drive the joints (BIG KANI uses MG996 servos).
- Two NCR18650B 3.7V 3400mAh lithium cells form the battery.
- A 5V UBEC regulator provides regulated power.
Connections
- The two batteries supply power through the 5V UBEC regulator to the robot's electronics.
- The repository includes a PCB Gerber set (KANI_ver_1.2) and Fritzing schematic files that show the connections between parts.
Schematics, boards and diagrams
- PCB/Gerber_PCB - KANI_ver_1.2Gerber (PCB manufacturing)
- Photos/1_Electronic_circuit_1.jpgDiagram
- Photos/1_Electronic_circuit_2.jpgDiagram
- Photos/1_Electronic_circuit_3.jpgDiagram
- Photos/1_Electronic_circuit_4.jpgDiagram
- Photos/1_Electronic_circuit_5.pngDiagram
- Photos/WebFormat/1_Electronic_circuit_1.jpgDiagram
- Photos/WebFormat/1_Electronic_circuit_2.jpgDiagram
- Photos/WebFormat/1_Electronic_circuit_3.jpgDiagram
- Photos/WebFormat/1_Electronic_circuit_4.jpgDiagram
- Photos/WebFormat/1_Electronic_circuit_5.pngDiagram
- Schemas/Quadruped_Robot_Schema.fzzFritzing


