Hexapod v2 (Linkit 7697)
A six-legged hexapod robot with 18 servo joints, controlled from a mobile phone over Bluetooth Low Energy by a Linkit 7697 board.
- Other
- Open source
- arduino
- 3D printable
Suggested by Robotheca, created by @SmallpTsai (opens in a new tab), from github.com/SmallpTsai/hexapod-v2-7697 (opens in a new tab). Pinned to commit 32d5391 (opens in a new tab).
- Hardware license
- GPL-3.0-only (opens in a new tab)
- Software license
- GPL-3.0-only (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
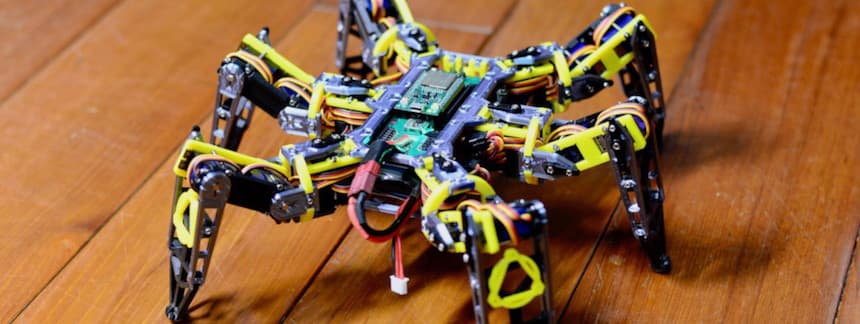
3D preview converted from github.com/SmallpTsai/hexapod-v2-7697 at 32d5391, under GPL-3.0-only. View the original files from GitHub (9.9 MB) (opens in a new tab)
- Power
- 7.4 V
What it can do
Written by Robotheca from the project's documents.
- Remote-controlled hexapod robot that moves forward, backward, turns and rotates, operated from a phone over Bluetooth Low Energy.
- Six legs with three joints each, driven by 18 servo motors (TowerPro MG92B).
- Calibration mode lets the user adjust each servo so it aligns to center, entered by pressing the user button just after power-on.
- Gait path points are generated by a Python tool and included in the robot firmware as a header.
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @SmallpTsai (README.md), under GPL-3.0-only.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Linkit 7697 microcontroller board, which handles Bluetooth control.
- 18 TowerPro MG92B servo motors, three per leg.
- Two NXP PCA9685 PWM driver chips to supply the servo control signals.
- Seven mini360 DC-DC step-down regulators: one provides 5V to the Linkit 7697, six provide 6V to the legs.
- 2S LiPo battery (7.4V) as the power source.
- Custom main and sub PCBs designed in Eagle 7.7.
Connections
- The Linkit 7697 controls the two PCA9685 boards over I2C.
- Each sub PCB carries one PCA9685; the sub PCBs differ by an I2C address jumper (SJ1), closed on the left board and left open on the right.
- Each mini360 regulator powers three servos of one leg at 6V.
- One mini360 regulator steps the battery voltage down to 5V for the Linkit 7697.
