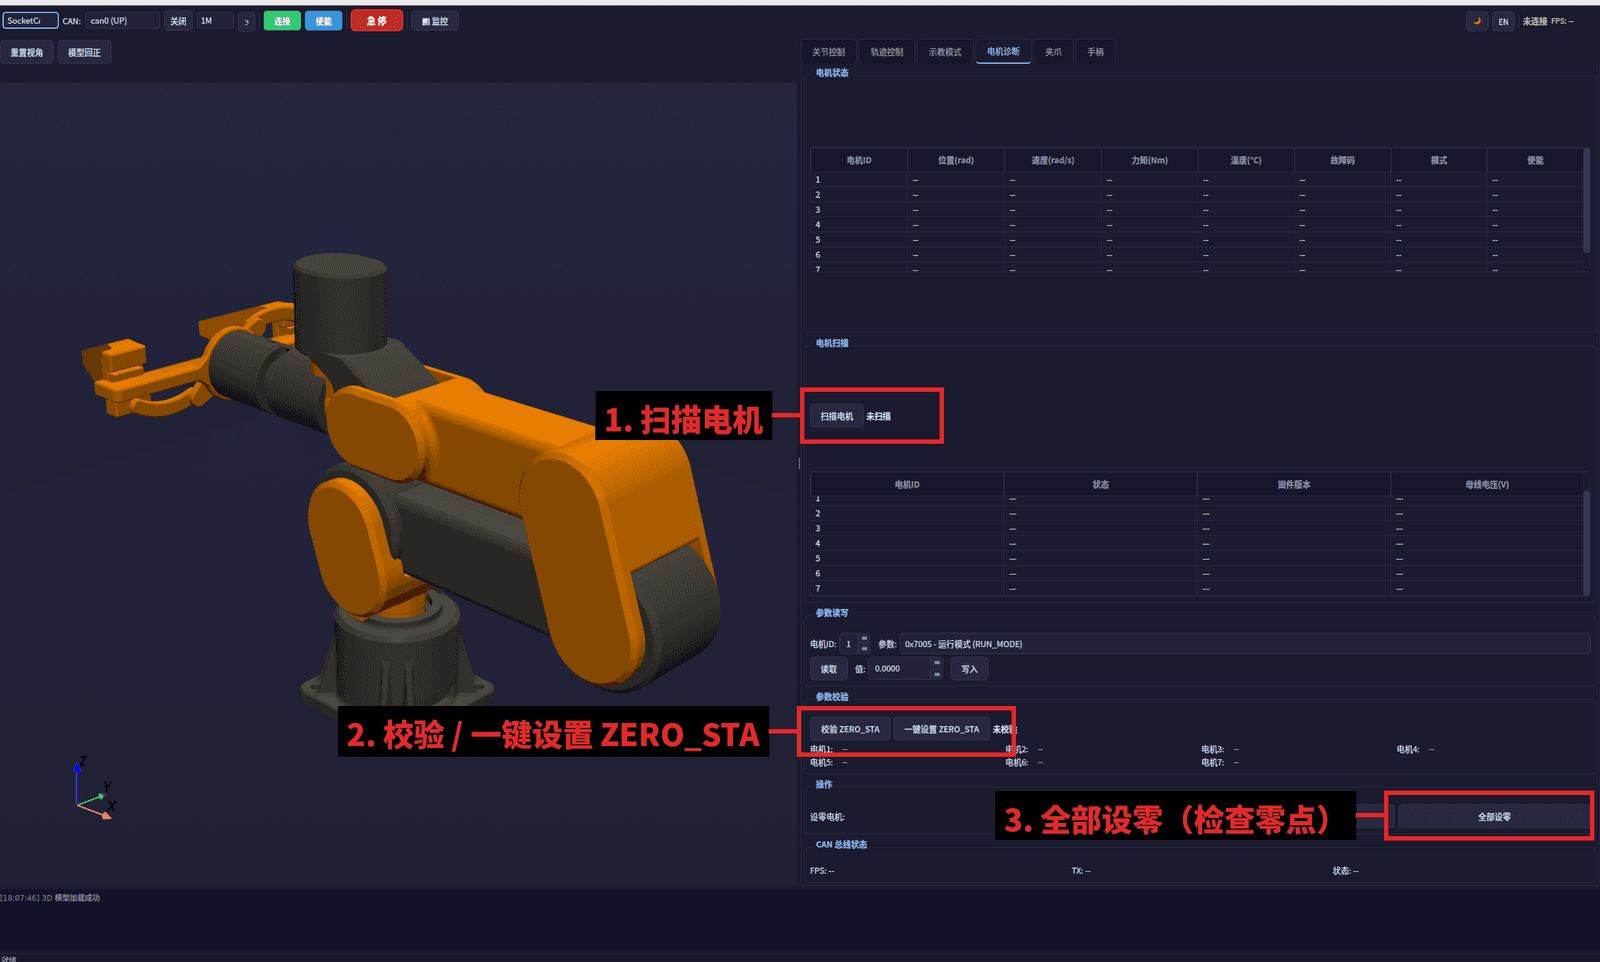
 Robot arm
EL-A3
A 7-DOF desktop robotic arm with a Python SDK and ROS2 control system for research and education.
- Level
- Advanced
- Buildability
- 75/100
- Buildable with some effort
- Cost
- Not stated
A ROS 2 framework of tools for launching multiple processes together and for writing tests that involve several processes.
Made by ROS 2.
Source on GitHub: github.com/ros2/launch (opens in a new tab). Facts read at commit a46664a (opens in a new tab).
Read by Robotheca from LICENSE (opens in a new tab) (Apache-2.0) at commit a46664a (opens in a new tab), on 16 Oct 2026.
Written by Robotheca from the project's README (opens in a new tab) at commit a46664a.
Checked on GitHub on 16 Oct 2026.
Robot armA 7-DOF desktop robotic arm with a Python SDK and ROS2 control system for research and education.
Found by Robotheca in el_a3_ros/el_a3_teleop/package.xml (opens in a new tab)
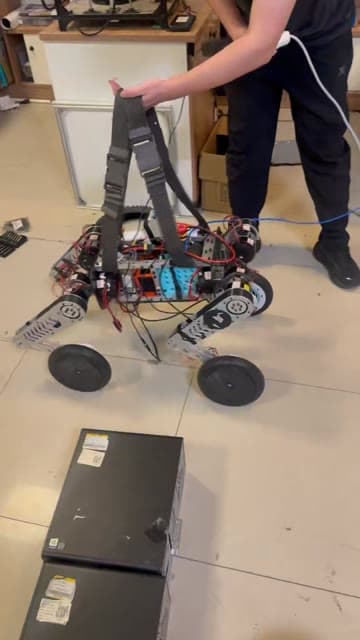 Wheeled
A 16-degree-of-freedom wheeled-legged robot designed for Robocon obstacle courses, combining reinforcement learning, MuJoCo simulation, and real-world deployment.
Found by Robotheca in 05_software/real/sim2real_ros2_v2/src/sim2real_bringup/package.xml (opens in a new tab)
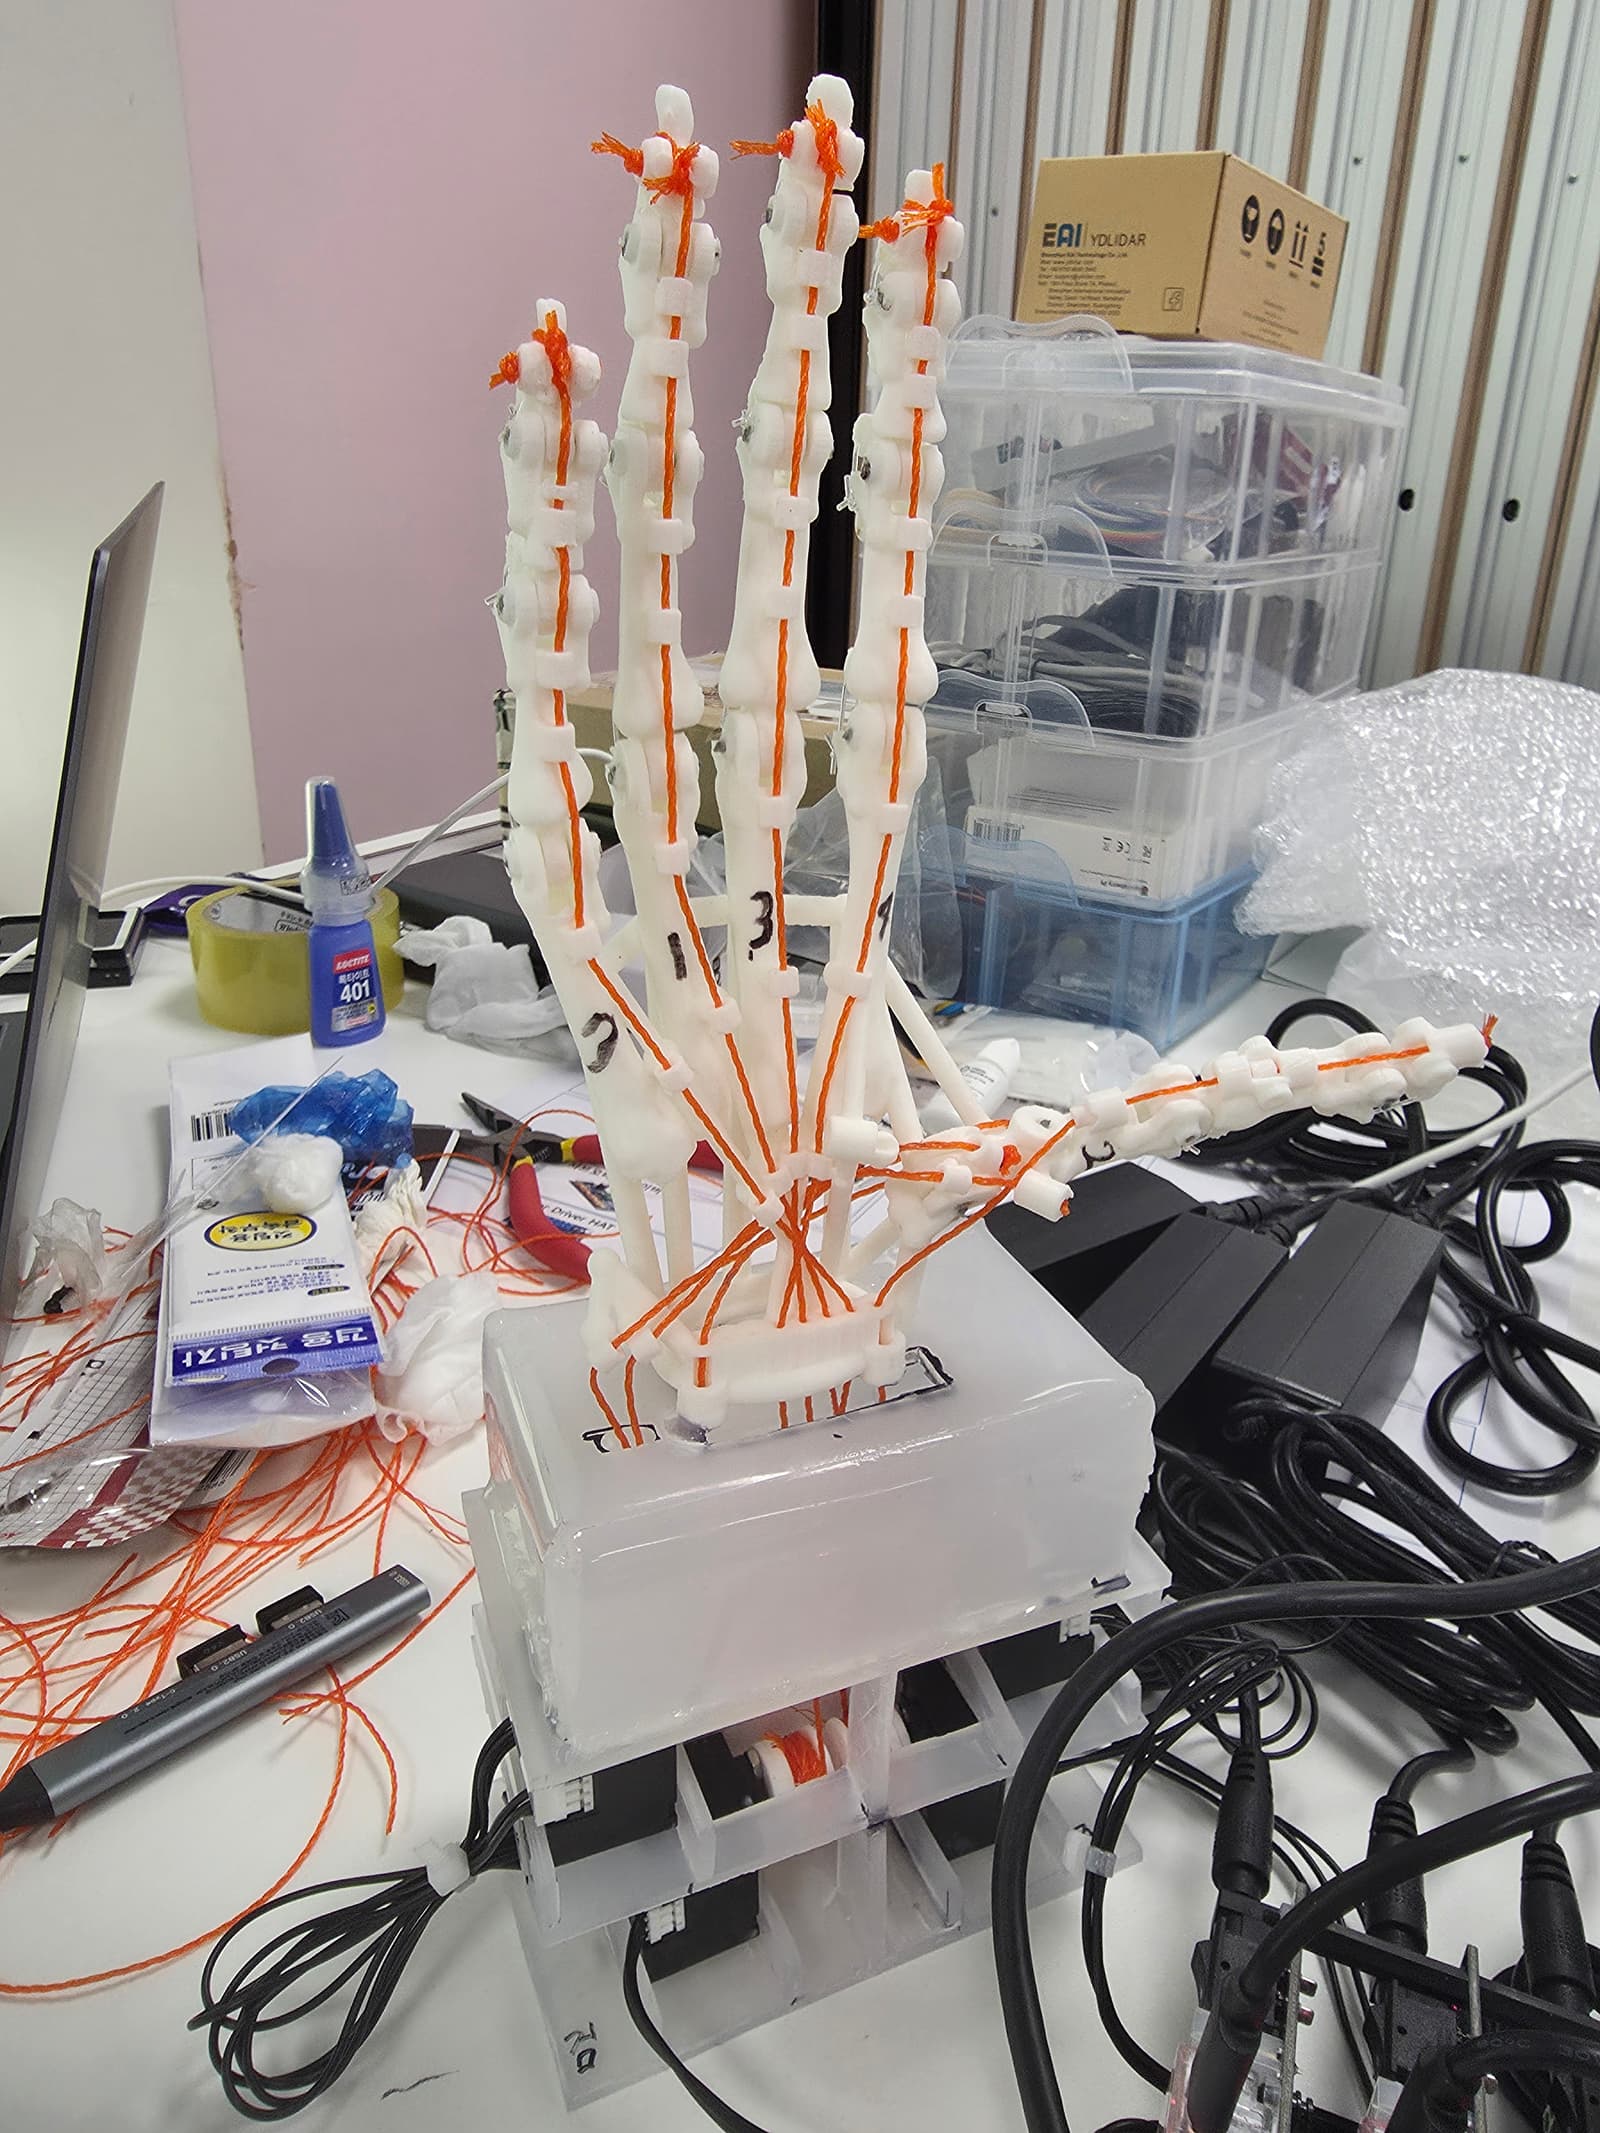 Other
A tendon-driven 7-axis robot hand that mimics the user's hand gestures in real time using MediaPipe vision and ROS 2.
Found by Robotheca in thing_ws/src/thing_bringup/package.xml (opens in a new tab)
Robotheca lists software as a reference: nothing is hosted or run here, and every fact links to where it was read.