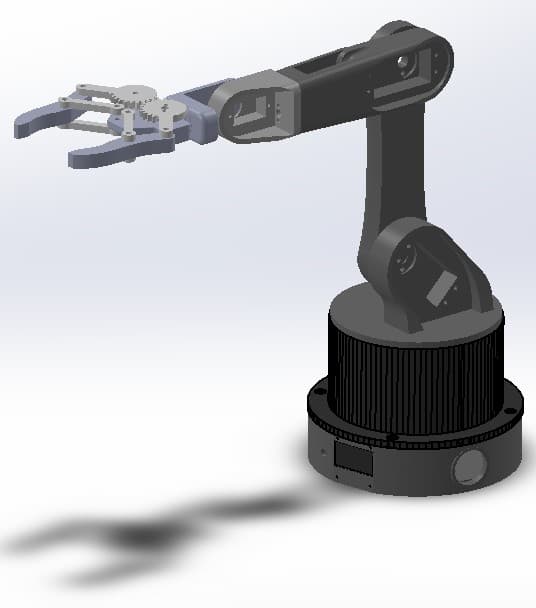
 3D render
Open source · free files
Mini-Arm
Robot arm · Intermediate
- Score
- Buildability 79 out of 100
- Cost
- $100≈ €89
Software
By ros-controls, from github.com/ros-controls/control_toolbox (opens in a new tab)
A ROS 2 C++ package offering classes and filter plugins that help in writing robot controllers.
Checked on GitHub on 6 Nov 2026.
Read by Robotheca from LICENSE (opens in a new tab) (Apache-2.0) and LICENSE.BSD-3-clause (opens in a new tab) (BSD-3-Clause) at commit f9d0ac3 (opens in a new tab), on 6 Nov 2026. The files name several licenses: a person at Robotheca set it on 9 Nov 2026.
Written by Robotheca from the project's README (opens in a new tab) at commit 92ad3fe, not by its creator.
Robotheca read the repository at two versions: the summary at 92ad3fe and the facts at f9d0ac3 (read on 6 Nov 2026).
Robotheca never hosts the code: each link goes to the creator's own page.
The robots on Robotheca that use it or can run it, each with how the link was found.
3D renderOpen source · free files
Robot arm · Intermediate
Found by Robotheca in ros2/miniarm_servo/CMakeLists.txt (opens in a new tab)
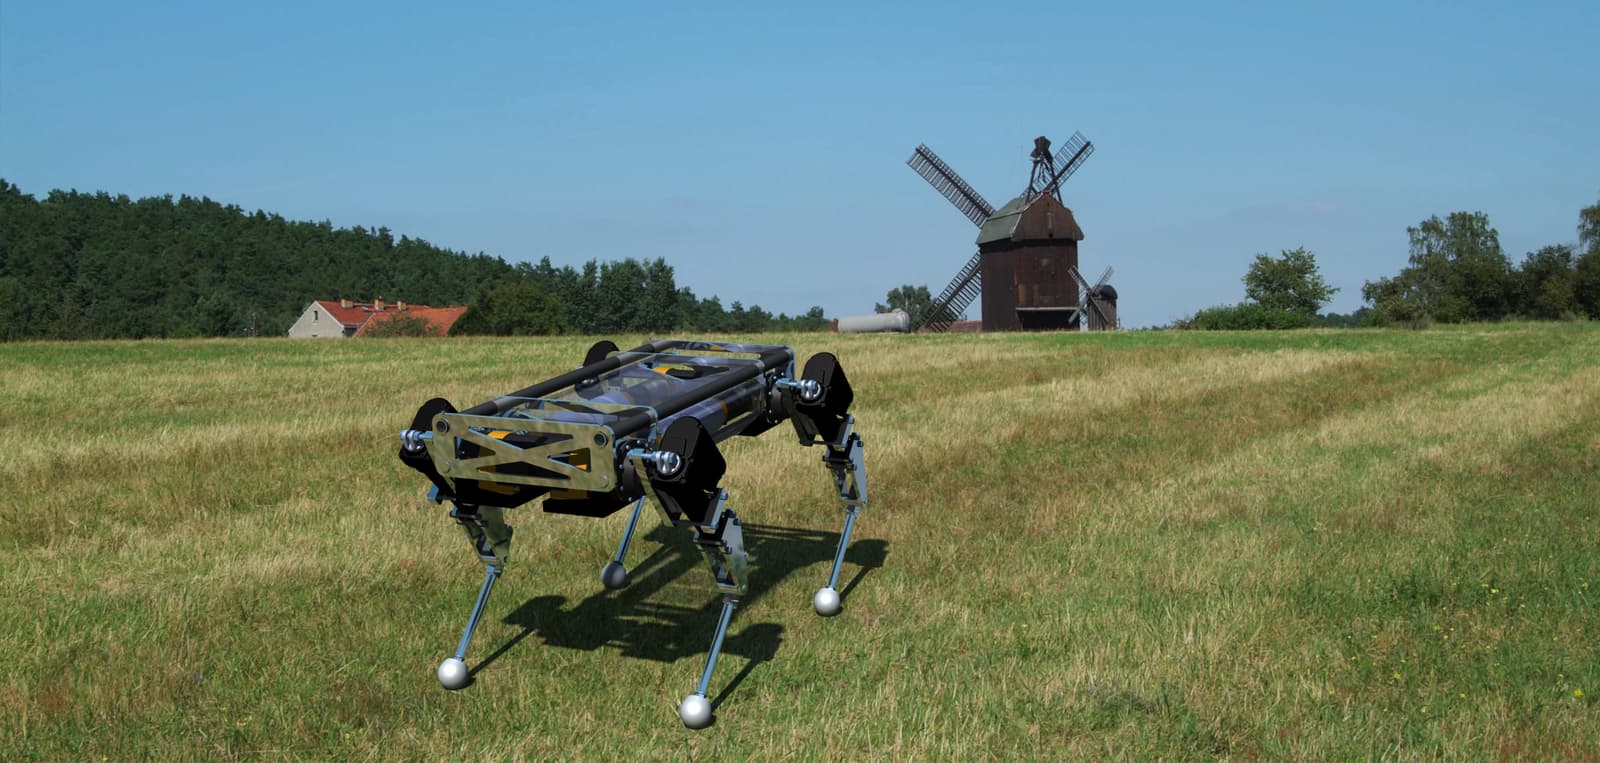
Found by Robotheca in popi_software/popi/popi_control/package.xml (opens in a new tab)
How to install it, in the creator's words: The project's website (opens in a new tab)
Robotheca doesn't review code. Read it before running it.
Robotheca lists software as a reference: nothing is hosted or run here, and every fact links to where it was read.