Photo on GitHub
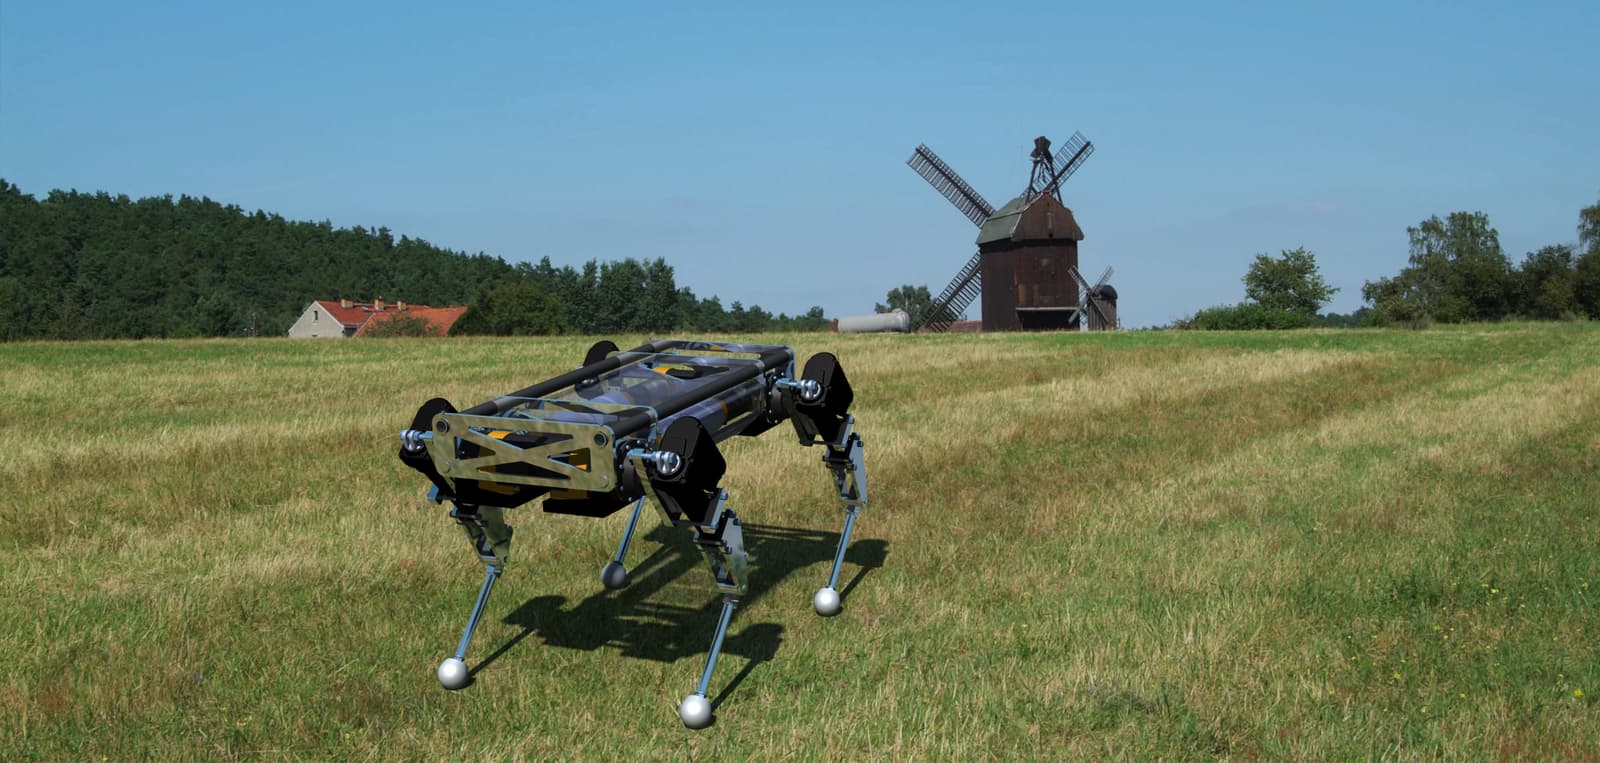
QuadrupedHighTorque-MiniDog
An open-source desktop quadruped robot featuring high-torque HTDW4438 motors, URDF models, and real-machine SDK for development and Sim2Real integration.
- No license
- Level
- Intermediate
- Buildability
- 60/100
- Buildable with some effort
- Cost
- Not stated