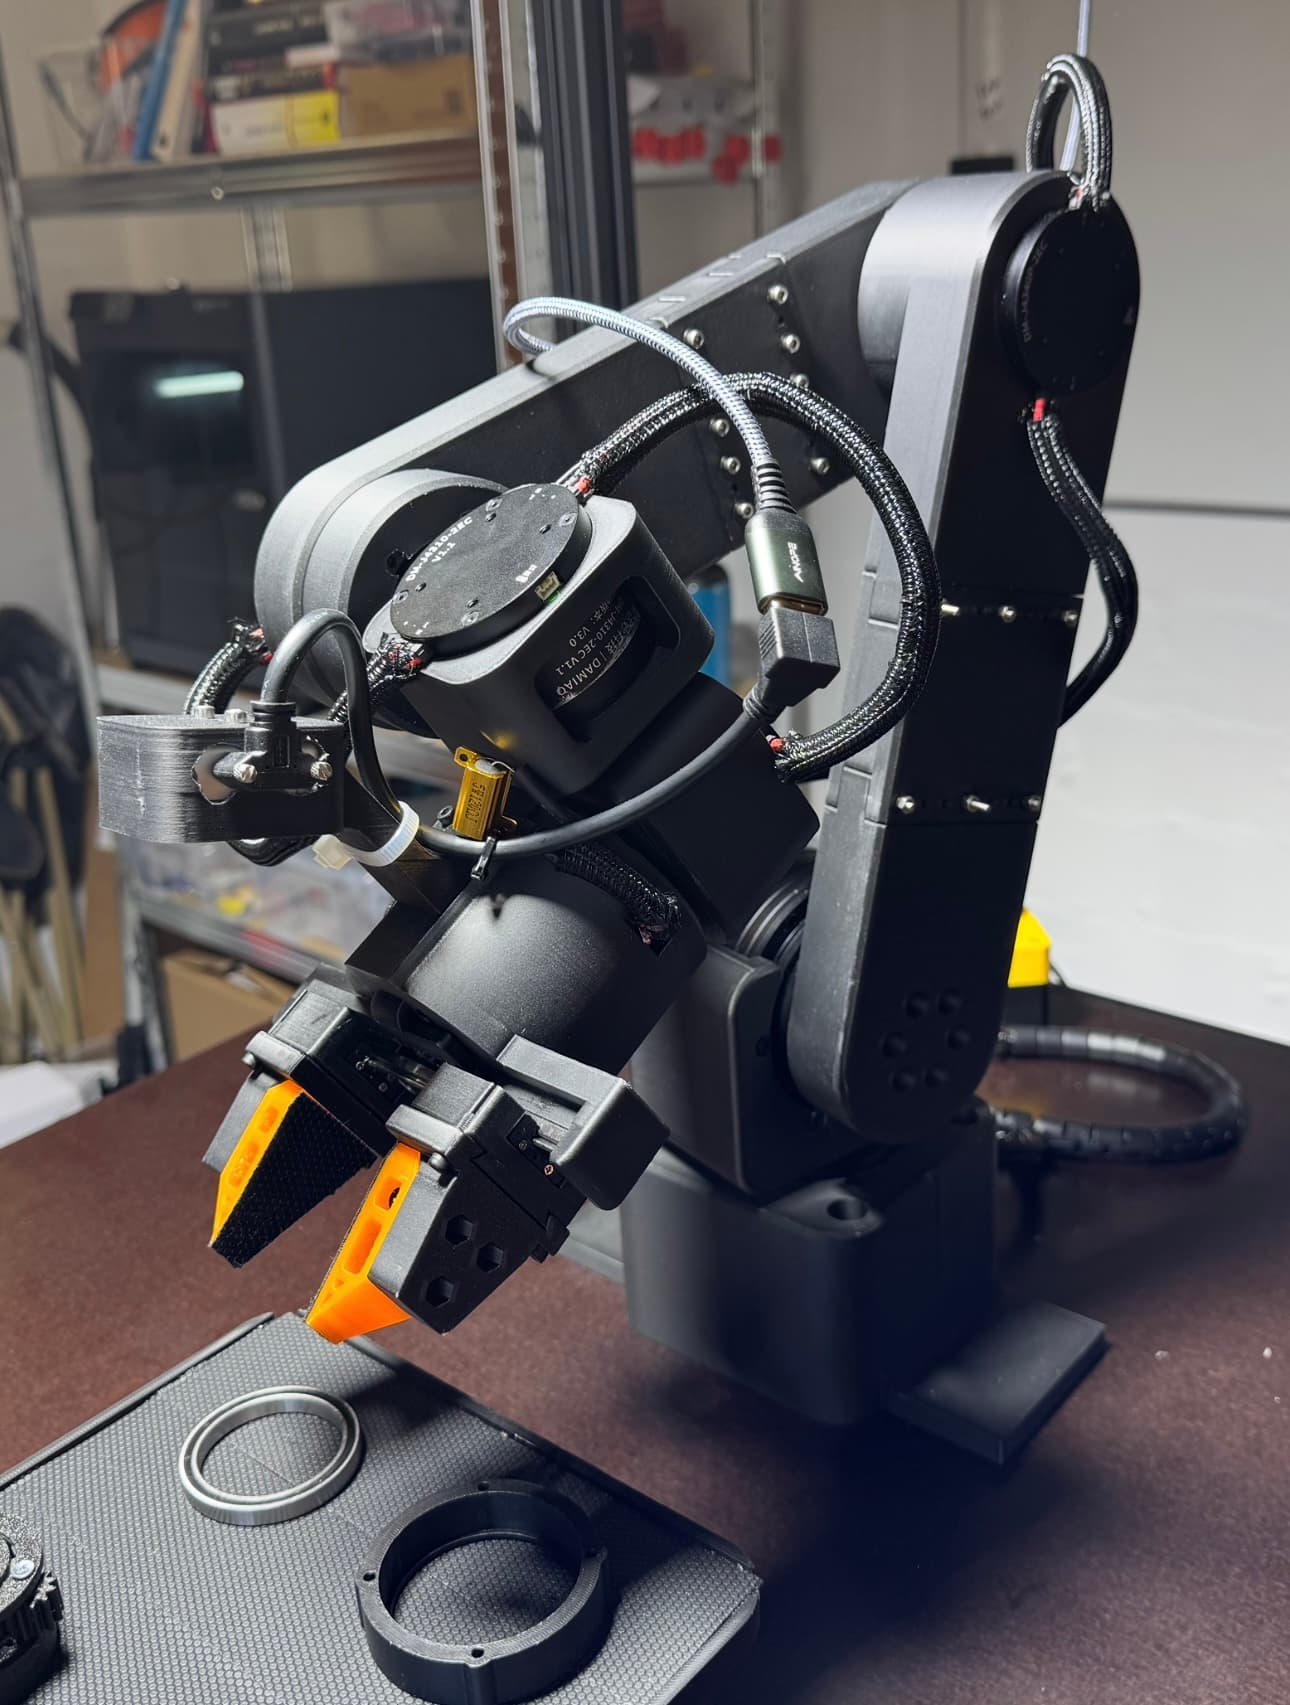
 Robot arm
AIRA
A 3D-printable 7-DoF robotic arm with native LeRobot integration for teleoperation, demonstration recording, and policy training.
- Works with AI
- Level
- Advanced
- Buildability
- 57/100
- Buildable with some effort
- Cost
- €2,000
A Python library giving developers common abstractions for Controller Area Network (CAN) buses, with utilities to send and receive messages across many hardware backends.
Source on GitHub: github.com/hardbyte/python-can (opens in a new tab). Facts read at commit b4f82ab (opens in a new tab).
Read by Robotheca from LICENSE.txt (opens in a new tab) (LGPL-3.0-only) at commit b4f82ab (opens in a new tab), on 16 Oct 2026.
Copyleft: Modified source must be published.
Written by Robotheca from the project's README (opens in a new tab) at commit b4f82ab.
Checked on GitHub on 16 Oct 2026.
Robot armA 3D-printable 7-DoF robotic arm with native LeRobot integration for teleoperation, demonstration recording, and policy training.
Found by Robotheca in pyproject.toml (opens in a new tab)
An open-source humanoid robotics research platform that minimizes leg inertia by concentrating mass near the limb roots using timing belts and parallel linkages.
Found by Robotheca in pyproject.toml (opens in a new tab)
Robotheca lists software as a reference: nothing is hosted or run here, and every fact links to where it was read.