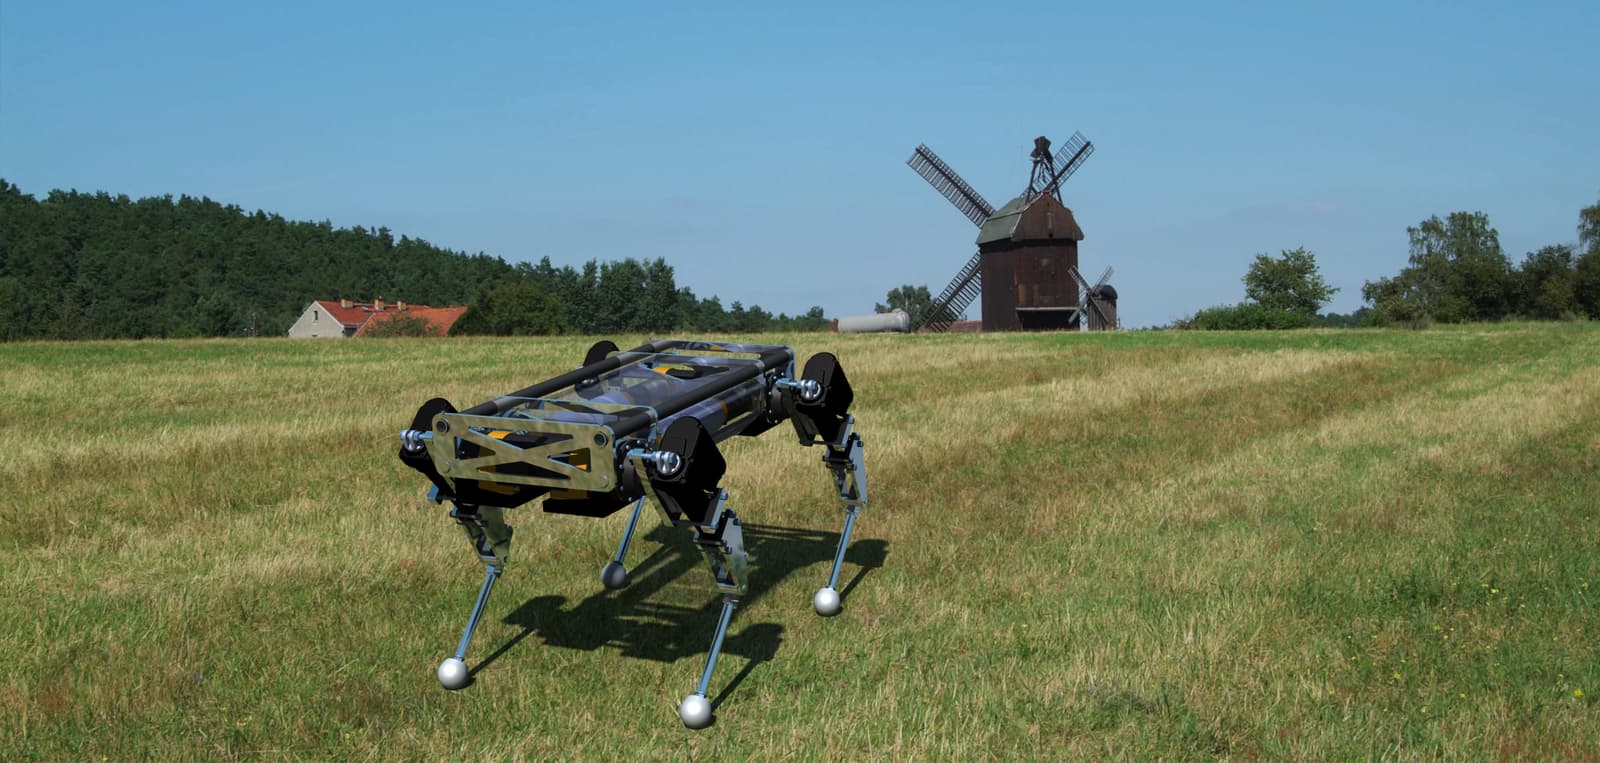
 Quadruped
POPI
POPI is an open-source quadruped robot designed as a student project, meant to be accessible for education and research and rebuildable by anyone.
- Level
- Advanced
- Buildability
- 70/100
- Buildable with some effort
- Cost
- Not stated
A C++ package that converts robot descriptions from URDF into KDL, the Kinematics and Dynamics Library's tree representation.
Made by ROS core stacks.
Source on GitHub: github.com/ros/kdl_parser (opens in a new tab). Facts read at commit 5a5c1b9 (opens in a new tab).
Read by Robotheca from LICENSE (opens in a new tab) (BSD-3-Clause) at commit 5a5c1b9 (opens in a new tab), on 16 Oct 2026.
Written by Robotheca from the project's README (opens in a new tab) at commit 5a5c1b9.
Checked on GitHub on 16 Oct 2026.
QuadrupedPOPI is an open-source quadruped robot designed as a student project, meant to be accessible for education and research and rebuildable by anyone.
Found by Robotheca in popi_software/towr/xpp/xpp_vis/package.xml (opens in a new tab)
Robotheca lists software as a reference: nothing is hosted or run here, and every fact links to where it was read.