Project files
README.md
Machine-translated by Robotheca from the original in Chinese (opens in a new tab). License: CERN-OHL-W-2.0 (opens in a new tab).
RP1 Mechanical Design
This directory provides the RP1 mechanical design source files, the Parasolid full-robot model, engineering drawings, and manufacturing files. Part quantities for each configuration are given in the full-robot BOM, and material and surface treatment requirements are given in the engineering drawings and the CMF specification sheet.
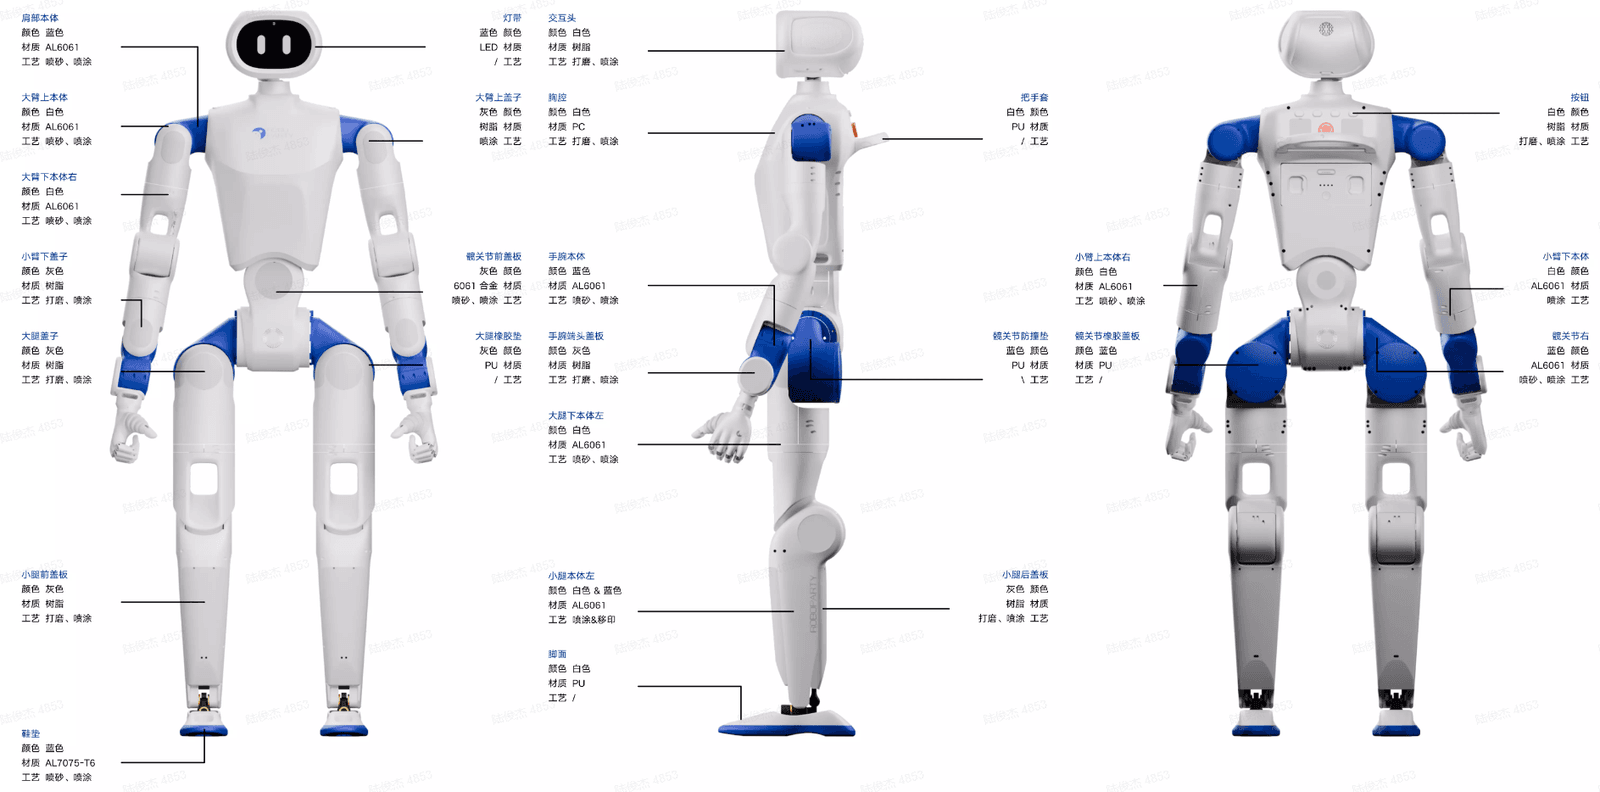
CAD Downloads
| File Package | Contents |
|---|---|
| RP1_SolidWorks_Source.zip (opens in a new tab) | SolidWorks assembly and part source files |
| RP1_Parasolid_Model.zip (opens in a new tab) | Parasolid full-robot model (.x_t) |
| RP1_Drawings.zip (opens in a new tab) | Editable SolidWorks engineering drawings (.SLDDRW) |
Fully extract the source file package, and open the complete robot from RP1_SolidWorks_Source/RP1.3.4整机.SLDASM, keeping the file locations within the package unchanged. When editing the drawings, place the .SLDDRW files from RP1_Drawings into the same directory as their corresponding source models. Each file package includes a license notice, and third-party files remain subject to their original terms.
Manufacturing Files
The processing BOM summarizes the quantities per part number for each unit, with 5DOF and 7DOF listed separately, and both correspond to the motion-control head configuration.
| Process | BOM and Files | Materials and Surface Finish |
|---|---|---|
| CNC machining | Processing BOM, Common parts, 5DOF, 7DOF | CMF spec sheet, CMF notes |
| 3D printing | Processing BOM, STEP model, PDF drawings | CMF spec sheet, CMF notes |
| Rubber parts | Processing BOM, STEP model, PDF drawings | CMF spec sheet, CMF notes |
The part number and revision suffix in the file names are used to match the drawings and models.
Files by @Roboparty, at commit 99c17ac, read from GitHub in your browser. Hardware license: CERN-OHL-W-2.0; software license: CERN-OHL-W-2.0. Robotheca doesn't review code: read it before running it.