Project files
9 KB
Machine-translated by Robotheca from the original in Chinese (opens in a new tab). License: GPL-3.0-only (opens in a new tab).
Pineapple Dog – A low-cost, large-scale, fully open-source quadruped robot hardware and software project
1 Introduction
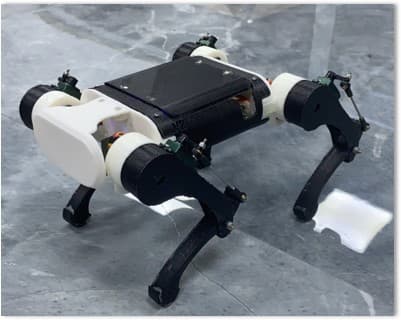
This project is the main open-source repository for the Py-Apple Dog (菠萝狗). The project aims to design and build a low-cost, easy-to-DIY open-source quadruped robot. It emphasizes multi-platform compatibility and serves as a comprehensive open-source quadruped robot project. It consists of four sub-projects (click to visit the corresponding GitHub repositories). The main repository will host the latest combined versions of Dynamics, Controller, and Structure for easy download:
-
Py-Apple Dynamics Series – Open-Source Quadruped Control Software (opens in a new tab)
-
Py-Apple Controller Series – Open-Source Universal Quadruped Controller (opens in a new tab)
-
Py-Apple Structure Series – Open-Source Quadruped Mechanical Structure (opens in a new tab)
-
Py-Apple BLDC Series – Open-Source Brushless Quadruped Robot!! (opens in a new tab)
The four projects complement and coordinate with each other, each updating independently while collectively forming a large-scale, comprehensive open-source quadruped robot hardware and software project. If you like the project, please give it a triple-tap on Bilibili and star the repository! For detailed project information, click here (opens in a new tab)
| Motion Performance | Remote Control Features | Balance Performance | Secondary Development Interface | AI Features |
|---|---|---|---|---|
| 8DOF kinematic inverse solution | RC transmitter control | Static self-stabilization | Serial communication interface | Line-following program |
| VMC algorithm | Web-based online control | WALK gait dynamic self-stabilization | Child-friendly graphical block programming | Color recognition and tracking program |
| Spatial linkage angle compensation | Web-based online parameter adjustment | Fall recovery | ||
| Pitch, roll attitude control | ||||
| Height control | ||||
| Supports custom mechanical structure dimension parameters |
2 User Support and Discussion Forums
The project is accompanied by comprehensive user support materials and discussion groups. Please visit:
- User support QQ Group 1 (quadruped robot dog with servos discussion group): 1071643412
- User support QQ Group 2 (brushless quadruped robot dog discussion group): 1005923565
- Official configuration documentation: http://padog.com.cn/#/ (opens in a new tab)
- Official Gitee repository (faster download of materials within China): ream_d (ream_d) - Gitee.com (opens in a new tab)
- Project demo video browsing (Bilibili): 灯哥开源四足机器人 (opens in a new tab)
4 Open-source Development Information
- Py-Apple Dynamics GitHub repository (opens in a new tab)
- Py-Apple Controller GitHub repository (opens in a new tab)
- Py-Apple Structure GitHub repository (opens in a new tab)
- For secondary development tutorials and methods to participate in various open-source projects, please click on the respective GitHub repositories to view.
- QQ group for developers of the Pineapple Dog open-source quadruped robot project: 960502665
5 Py-Apple Dog Project Setup Method
-
If you are a beginner
-
First, study the basic videos by Light Brother from Channel 1 (opens in a new tab) and Channel 2 (opens in a new tab) (open on a computer; mobile may not open the channels)
-
Visit Py-Apple Structure Series – Open-source Quadruped Mechanical Structure (opens in a new tab) and follow the instructions inside to print and assemble the mechanical structure and parts
-
Visit Py-Apple Controller Series – Open-source Universal Quadruped Controller (opens in a new tab) and follow the instructions inside to manufacture the main control board
-
Visit Py-Apple Dynamics Series – Open-source Quadruped Control Software (opens in a new tab) and follow the instructions inside to download and flash the quadruped robot control program
-
Follow the videos above to learn robot operation and start enjoying it
-
Join the project discussion group on QQ and the discussion forum to find like-minded enthusiasts
-
Continue learning and try secondary development according to Secondary Development Guide (opens in a new tab)
-
If you already have some experience (build the project directly)
-
Visit Py-Apple Structure Series – Open-source Quadruped Mechanical Structure (opens in a new tab) and follow the instructions inside to print and assemble the mechanical structure and parts
-
Visit Py-Apple Controller Series – Open-source Universal Quadruped Controller (opens in a new tab) and follow the instructions inside to manufacture the main control board
-
Visit Py-Apple Dynamics Series – Open-source Quadruped Control Software (opens in a new tab) and follow the instructions inside to download and flash the quadruped robot control program
-
Follow the videos from Channel 1 (opens in a new tab) to learn robot operation and start enjoying it
-
Join the project discussion group on QQ and the discussion forum to find like-minded enthusiasts
-
Continue learning and try secondary development according to Secondary Development Guide (opens in a new tab)
-
If you are interested in learning about robot control principles, you can study the quadruped robot theory videos from Channel 1 (opens in a new tab) and Channel 2 (opens in a new tab)
-
One-stop purchase of all electronic components
The entire Py-Apple Dog project is fully open-source, so you can DIY everything yourself.
However, if you want a one-stop solution to purchase all hardware, mechanical parts, and screws, consider my DIY kit—absolutely a fair price. Your purchase supports me and the open-source project. Buy me dinner and chicken legs for staying up late to develop Py-Apple Dog and create quadruped robot tutorials—add coffee too!!
Official Taobao store: Dengge Open Source (opens in a new tab)
5 Py-Apple Quadruped Robot Project Contributors
6 Accompanying tutorials (click to enter)
For this open-source quadruped robot, we have carefully prepared a series of accompanying quadruped robot tutorials (three series in total)
-
Light Brother Series (New Version) – Updating
Latest update: 2021.4.5 Light Brother's 0-Basis DIY Quadruped Robot Guide (New Version) (opens in a new tab)
-
Light Brother Series (Old Version)
1. Light Brother's 0-Basis DIY Quadruped Robot Guide (1) – Introduction (opens in a new tab)
-
Light Sister Series
1. Light Sister Quadruped Robot Math Mini-Lesson (1) – Rotation Transformation (opens in a new tab)
-
Code Text Explanation
Py-apple Dynamics 6.0 Code Text Explanation by LiangYuHao (opens in a new tab)
Files by @ToanTech, at commit d2bb34f, read from GitHub in your browser. Hardware license: GPL-3.0-only; software license: GPL-3.0-only. Robotheca doesn't review code: read it before running it.