← HRVL-Gbot (gazebot)
Project files
1 KB
Machine-translated by Robotheca from the original in Korean (opens in a new tab). License: GPL-3.0-only (opens in a new tab).
HRVLGbot_CadFiles
- Robot Name: HRVL-Gbot (gazebot)
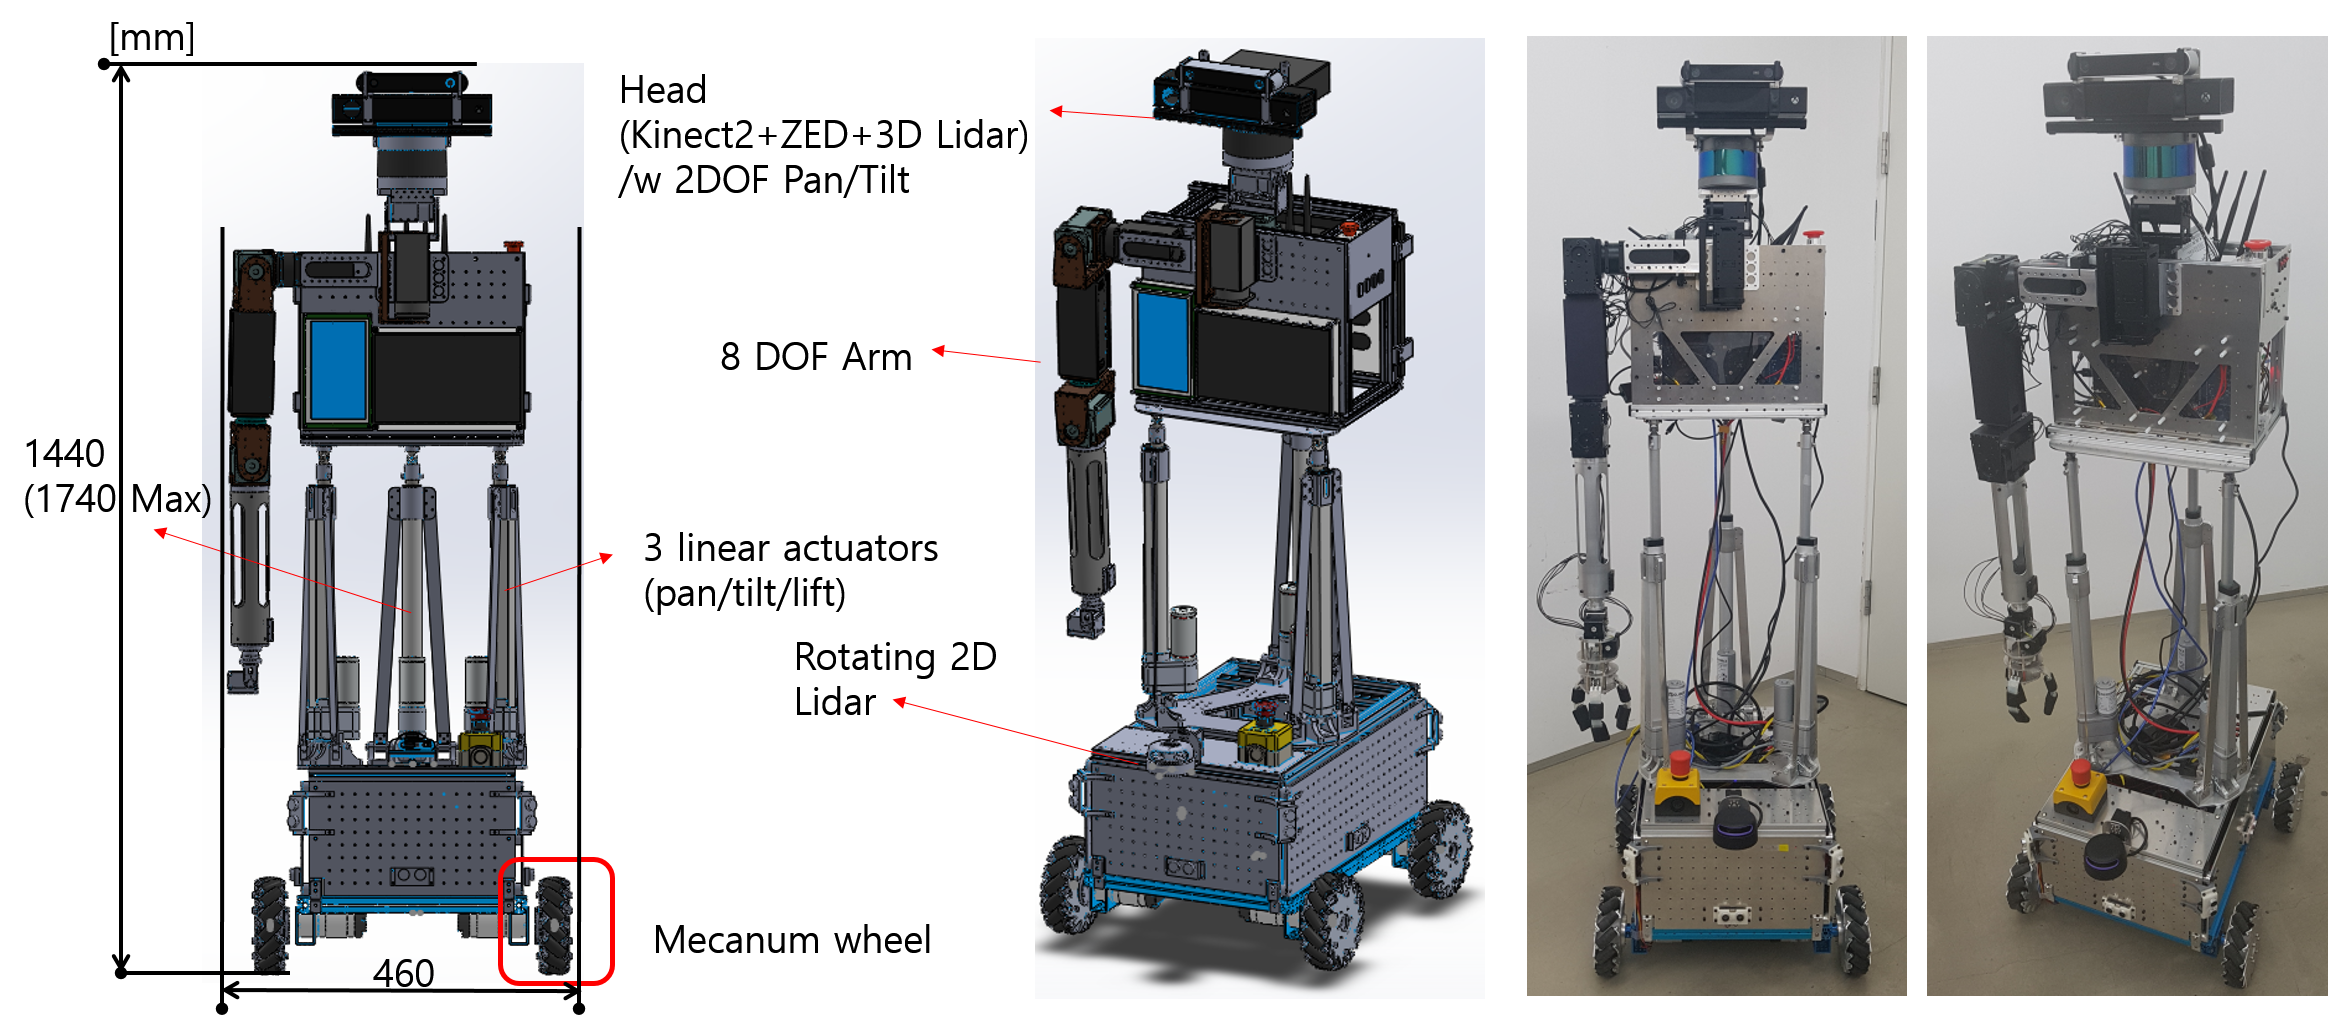
- Multi-purpose Robot Platform for Navigation/Gaze Control researches (Multi-purpose humanoid robot platform for navigation/gaze control research)
- 7 DOF ARM + 3 DOF waist(roll/pitch+Lift) + Mecanum Platform
- Kinect2 + ZED + Lidar mounted Pan-Tilt Robot Head
How to use it
- Used program: Solidworks 2017
- Main assembly file: WholeRobot_SIMPLE_TOTAL.SLDASM
License
- GNUv3
Owner
- HRVL(Human-centered Robotics and Vision Lab) @ Daejeon University
- Prof. Jeong-Ki Yoo
Acknowledgement
This work was supported by the National Research Foundation of Korea(NRF) grant funded by the Korea government(MSIT) (No. 2016R1C1B2012348).
Files by @ohora23, at commit 7a8c737, read from GitHub in your browser. Hardware license: GPL-3.0-only; software license: GPL-3.0-only. Robotheca doesn't review code: read it before running it.