Project files
1 KB
Machine-translated by Robotheca from the original in Chinese (opens in a new tab). License: MIT (opens in a new tab).
[Open-Source Quadruped Robot] HCRT-DOG
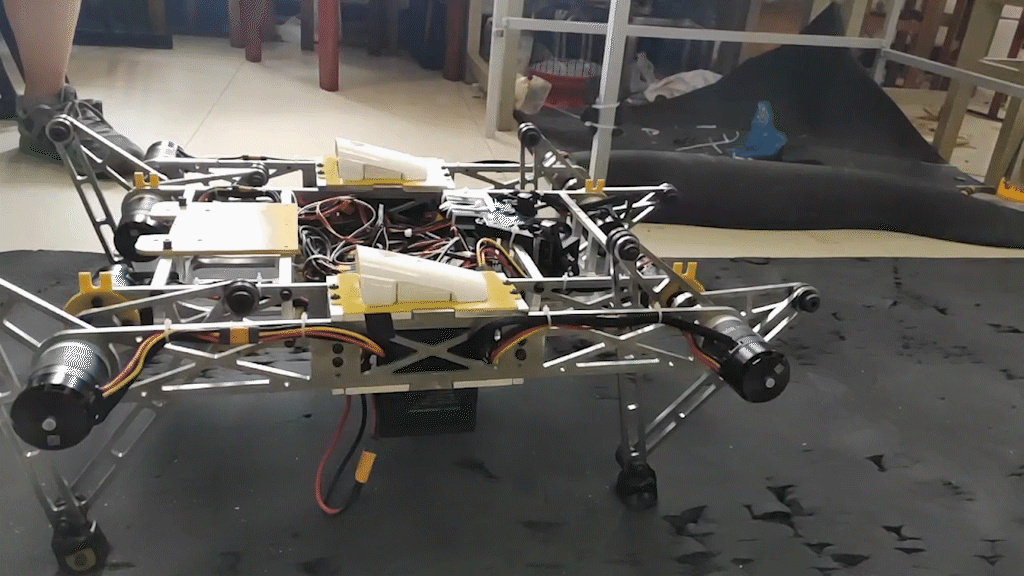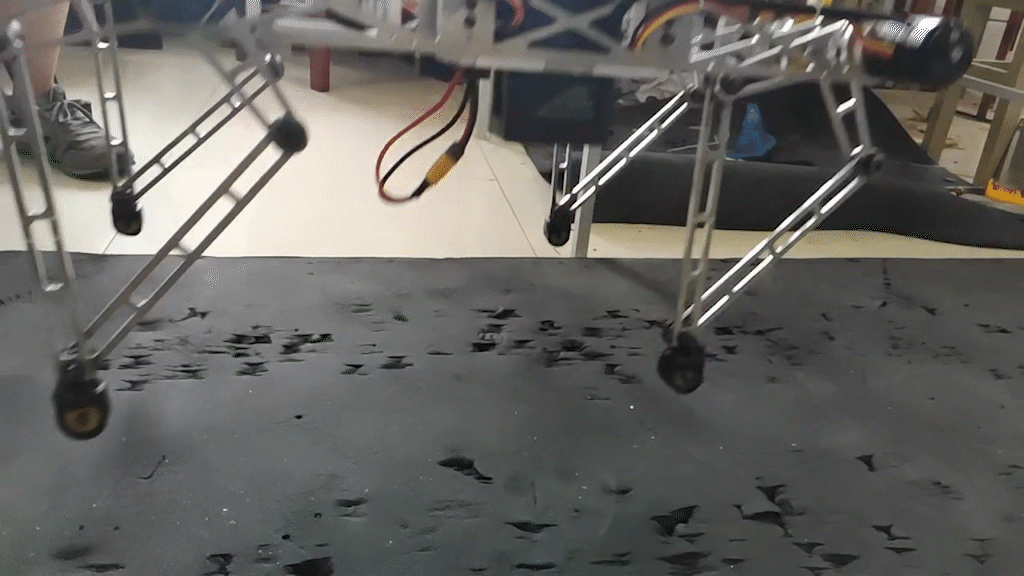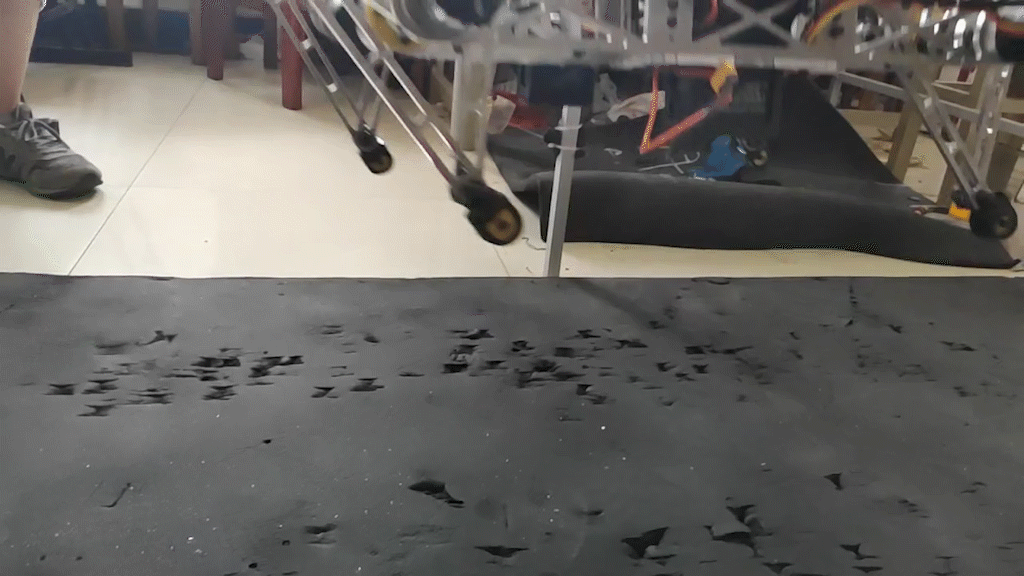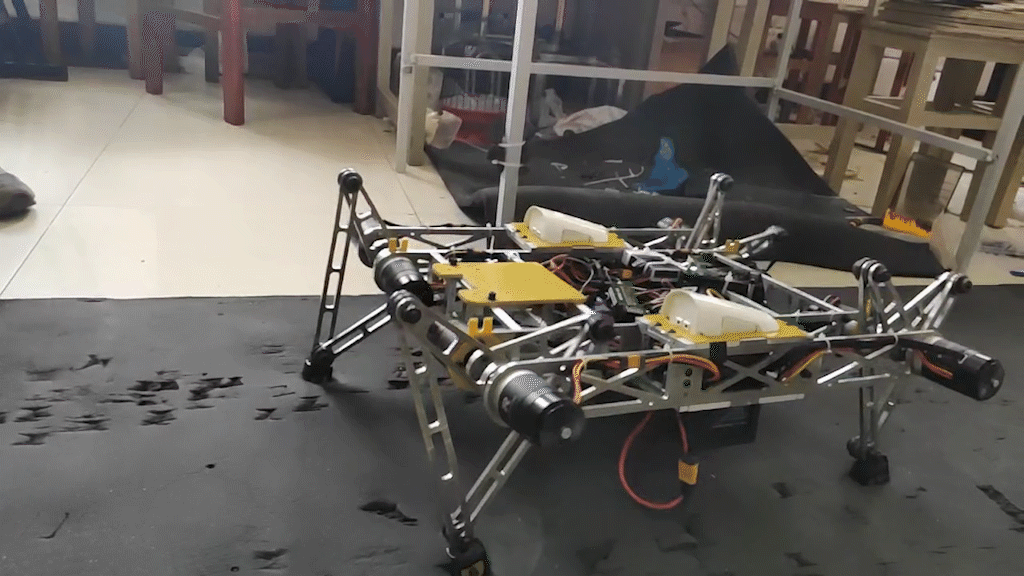
This project is a parallel quadruped robot. Each leg is driven by two motors, with a total of four legs and eight motors. It is expected to achieve four gaits, from slow to fast: walking gait (three-foot support), trotting gait (two-beat gait), cantering gait, and galloping gait.
This software follows the MIT open-source license. The author retains copyright with no other restrictions, but you must include a statement of the original MIT license in your software. Due to limited time and ability, there are many shortcomings. You are welcome to leave a message in the
Issuessection on GitHub.
For more information, please visit:
My blog: https://yltzdhbc.top/HCRT-DOG (opens in a new tab)
GitHub: https://github.com/yltzdhbc/HCRT-DOG (opens in a new tab)
Gitee: https://gitee.com/yltzdhbc/HCRT-DOG (opens in a new tab)
Files by @yltzdhbc, at commit eff71df, read from GitHub in your browser. Hardware license: MIT; software license: MIT. Robotheca doesn't review code: read it before running it.