Project files
1 KB
Machine-translated by Robotheca from the original in Chinese (opens in a new tab). License: MIT (opens in a new tab).
README
This project is an open-source project for the bicycle track race of the outdoor competition in the National College Students Intelligent Vehicle Competition. (Previously won the first prize in the Intelligent Vehicle Competition)
1. Project Structure Description
This project stores all the source code, hardware architecture, and software architecture required for the balancing bicycle project. Below is the project structure description for the bicycle project:
- main branch: Aggregates and stores all code.
- Calculation_Unit branch: Calculation unit code, mainly storing processing related to lane detection, obstacle recognition, and decision-making, which is the core part of the system's total calculation unit.
- Control_Unit branch: Control unit code, mainly storing control modules responsible for the balance, steering, forward, and backward kinematic operations of the vehicle body.
- Mechanical_Unit branch: Mechanical unit branch, mainly including the mechanical structure of the vehicle body, used for CNC machining and 3D printing, etc.
Note: The
betabranch contains test version code.
2. Implemented Functions
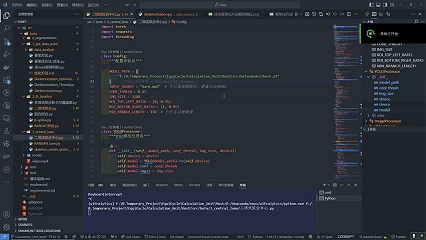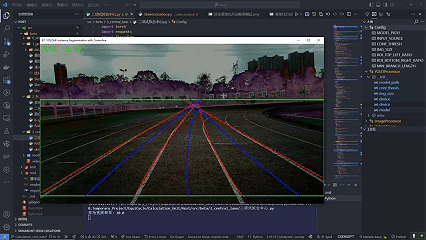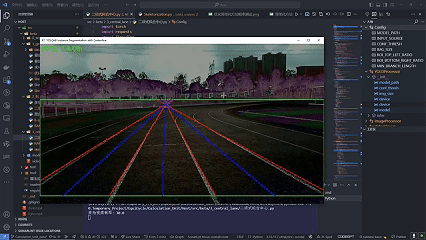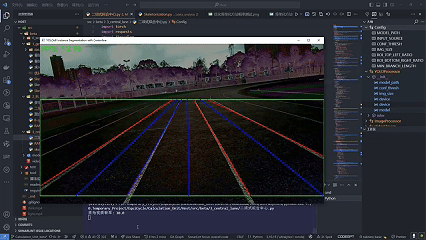
2.1 Vision Module
Interference Resistance Test (Crossed Wires, Shadows)
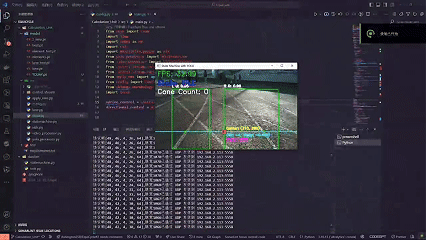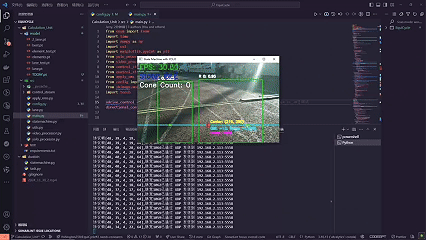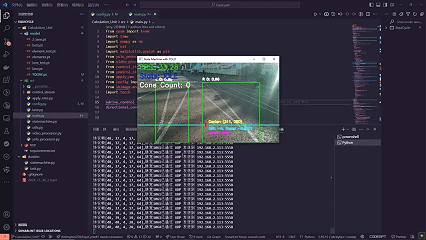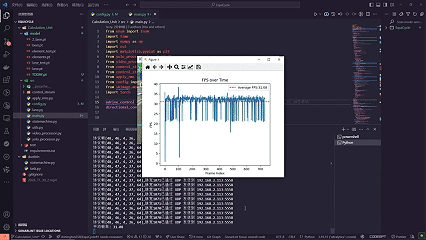
Light Variation Tests
-
Bright Light Test
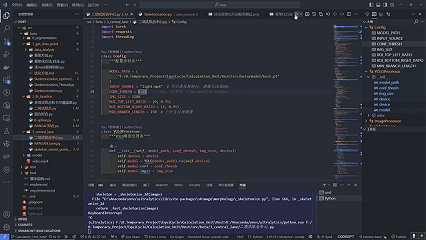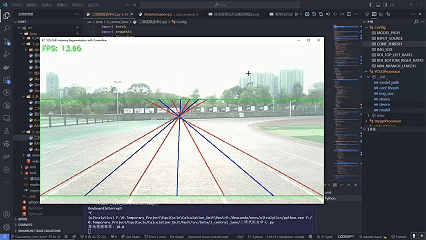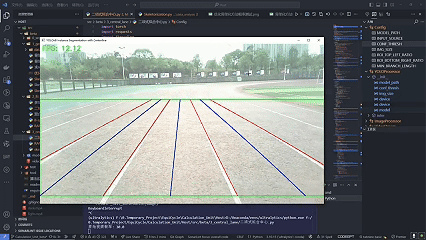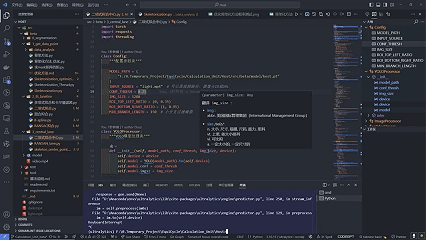
-
Low Light Test
2.2 Kinematics Module
Kinematics Module
- Remote control / keyboard control
- Automatic control (PID, LQR)
Files by @Ashington258, at commit e542f7f, read from GitHub in your browser. Hardware license: MIT; software license: MIT. Robotheca doesn't review code: read it before running it.